物理人工智能的全球坐标
40项国家与产业集群排名,350项企业、人物与机构入选记录。
390项
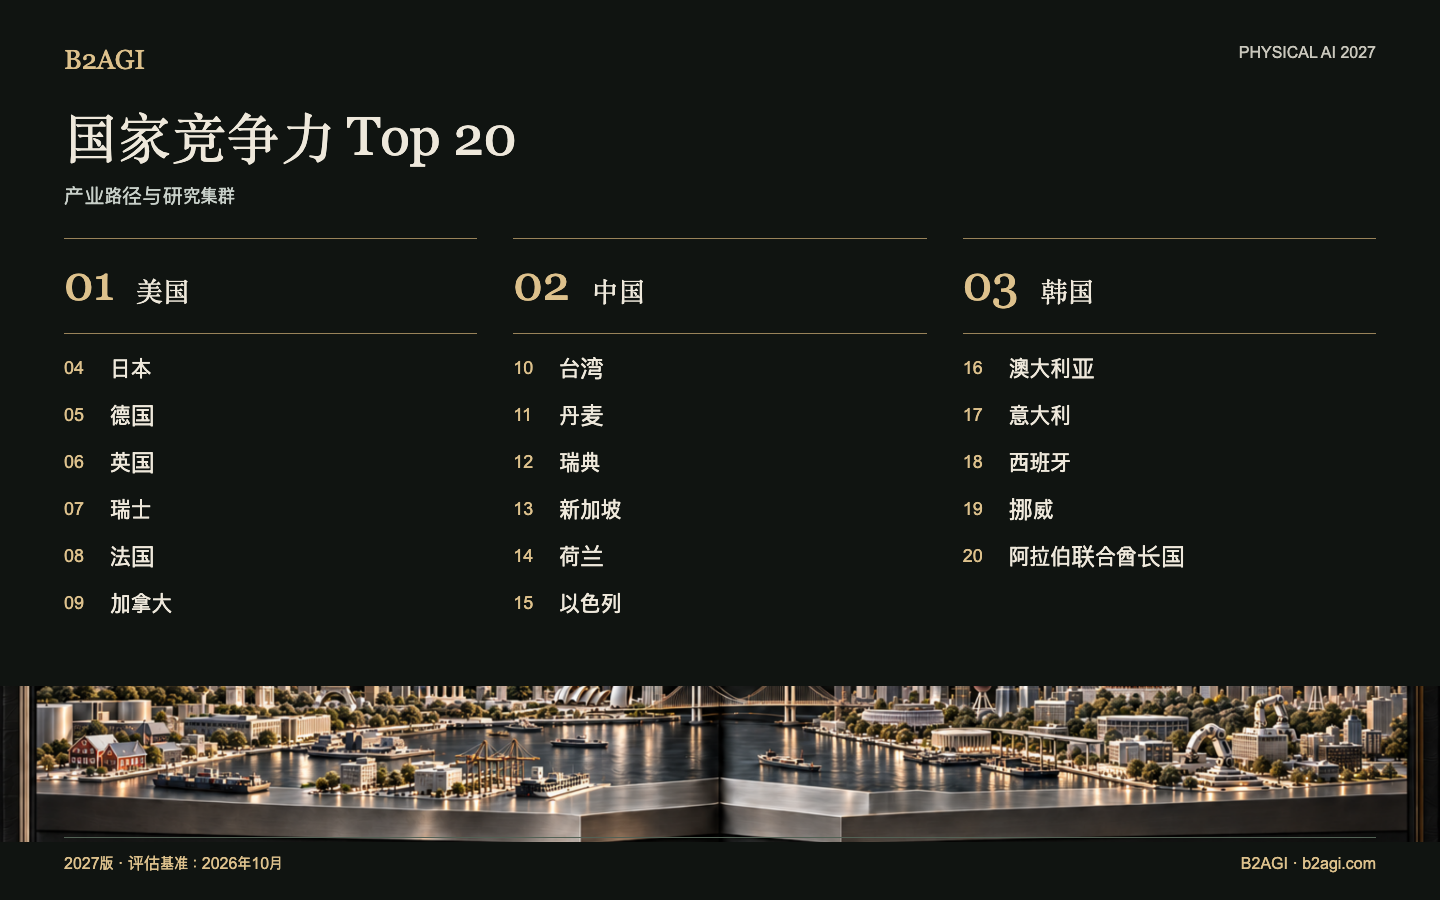
美国 country:01第1位
贡献
机器人平台、客户部署与增长资本
入选依据 · 英文原文
The United States brings general-purpose models and robotics platforms into named customer tasks, supported by growth capital and operating records.
证据范围 · 英文原文
IFR 2025 installation data, operating and customer records, technical platforms, completed financing and operating permissions.
来源
中国 country:02第2位
贡献
机器人硬件与集成制造网络
入选依据 · 英文原文
China combines sensing, robot hardware and electronics manufacturing with product development and dense supply chains. Industrial-robot demand supports this manufacturing base.
证据范围 · 英文原文
IFR 2025 industrial-robot installations and domestic supplier share; manufacturer and customer records; research, financing, testing and shared development infrastructure.
来源
韩国 country:03第3位
贡献
机器人协同、学习型控制与研究成果商业化
入选依据 · 英文原文
Korea combines research investment with NAVER's cloud-based robot coordination, KAIST's learned locomotion control and university-led robotics commercialization.
证据范围 · 英文原文
NAVER's internal operations; KAIST's July 2026 HOUND experiments and February 2026 report on technology-transfer and investment activity. The March 2026 testbed demonstration and planned external access retain separate stages. Economy-wide research indicators provide context.
来源
日本 country:04第4位
贡献
工厂流程中的感知与运动规划
入选依据 · 英文原文
Japan brings perception and motion generation into established manufacturing processes, building on robotics and precision-control capabilities.
证据范围 · 英文原文
JARA calendar-2025 production and shipments, IFR installations, robot-control and customer records. JARA includes dedicated manipulators; production and installation measures retain separate definitions.
来源
德国 country:05第5位
贡献
工业操作、集成与测试
入选依据 · 英文原文
Germany brings industrial customers, intelligent integration providers and external testing and approval into the same deployment pathway.
证据范围 · 英文原文
Manufacturing demand, customer-process integration, industrial fleets and testing services. Overseas customer installations retain their operating locations.
来源
英国 country:06第6位
贡献
端侧机器人模型与灵巧学习
入选依据 · 英文原文
The United Kingdom develops local robotics models and robot-learning hands through documented joint development.
证据范围 · 英文原文
Driving trials, DEX-EE and DemoStart research, model development, financing and reusable tools. Joint international research retains shared attribution.
来源
瑞士 country:07第7位
贡献
用于工业检测的学习型控制技术
入选依据 · 英文原文
Switzerland’s ANYmal brings learned control into industrial inspection workflows.
证据范围 · 英文原文
Learned inspection and locomotion, research-to-product transfer, institutional and financial context, with development and customer sites separately attributed.
来源
法国 country:08第8位
贡献
开放式机器人学习工具与操作模型
入选依据 · 英文原文
France provides open robot-learning tools and develops general-purpose manipulation models alongside hardware integrations.
证据范围 · 英文原文
Warehouse implementations, robot-learning tools, manufacturing integration, financing and testing access. Joint French-US development retains shared attribution.
来源
加拿大 country:09第9位
贡献
操作学习与自动驾驶卡车集成
入选依据 · 英文原文
Canada develops physical manipulation learning, industrial tools and truck-OEM integration through distinct product pathways.
证据范围 · 英文原文
Industrial robot suppliers, shared research assets and supervised freight development. Waterloo and Toronto activity retain separate locations.
来源
台湾 country:10第10位
贡献
半导体制造、封装与机器人技术基础设施
入选依据 · 英文原文
Taiwan combines semiconductor fabrication and packaging with R&D, robotics investment and industrial testing infrastructure.
证据范围 · 英文原文
NSTC 2024 R&D expenditure; TSMC fabrication and packaging; electronics and robotics records; ITRI testing and incubation infrastructure.
来源
丹麦 country:11第11位
贡献
移动物流与协作机器人平台
入选依据 · 英文原文
Denmark supplies AMRs for transport and collaborative robots for AI greenhouse harvesting, with named customer tasks.
证据范围 · 英文原文
UR and MiR platform supply, Odense development infrastructure, DTI incubation and Danish industry records. National turnover and local cluster activity retain separate scopes.
来源
瑞典 country:12第12位
贡献
面向产业应用的机器人研究与博士培养
入选依据 · 英文原文
Sweden connects robotics research and industrial tasks through WARA Robotics and WASP doctoral training, alongside ABB development, ISO standards work and Hexagon's humanoid programme.
证据范围 · 英文原文
WARA's December 2024 industry-linked challenge and WASP's May 2026 graduate statistic; domestic ABB development and multinational Hexagon activity retain their locations. The new ABB campus is scheduled for 2027.
来源
新加坡 country:13第13位
贡献
电力隧道巡检的本土集成
入选依据 · 英文原文
Singapore brings foreign robot hardware into power-tunnel inspection through local integration and operation.
证据范围 · 英文原文
Power-tunnel inspection, retail integration, local operators, research and institutional context; country and cluster profiles cross-reference shared events.
来源
荷兰 country:14第14位
贡献
仓储集成与自动化融资
入选依据 · 英文原文
The Netherlands combines a documented warehouse-automation installation with an automation-finance role serving an overseas site.
证据范围 · 英文原文
ASML equipment and R&D, domestic warehouse integration, testing services and separately located overseas automation finance.
来源
以色列 country:15第15位
贡献
操作技术开发与国家级AI算力
入选依据 · 英文原文
Israel develops observation-based physical manipulation and driver-assistance technology, supported by research investment and national AI computing access for academia and industry.
证据范围 · 英文原文
Manipulation development, eyes-on SuperVision assistance and acquisition records. January 2026 national computing infrastructure is operational; accelerator allocations extend over subsequent years.
来源
澳大利亚 country:16第16位
贡献
自动采矿与建筑施工的现场试验
入选依据 · 英文原文
Australia hosts autonomous construction at a solar site and shared physical testing by public research teams.
证据范围 · 英文原文
Komatsu's September 2025 Australian operating fleet, Rio Tinto Pilbara rail and drilling, and a separately staged construction pilot.
来源
意大利 country:17第17位
贡献
工业集成与仓储验证
入选依据 · 英文原文
Italy’s industrial robotics integration extends into Comau’s AI-enabled warehouse testing and validation for the European MASTERLY project.
证据范围 · 英文原文
IFR manufacturing installations, Italian automation supply and European testing infrastructure. Comau reported Decathlon warehouse validation on 9 September 2026; the customer warehouse location is not established by that release.
来源
西班牙 country:18第18位
贡献
机器人工程与AI检测技术开发
入选依据 · 英文原文
Spain hosts Barcelona robotics-platform development and an AI inspection development site.
证据范围 · 英文原文
Barcelona robot engineering, manufacturing robot demand, customer integration and shared European testing resources.
来源
挪威 country:19第19位
贡献
人形机器人工程与制造开发
入选依据 · 英文原文
1X’s April 2024 announcement describes development of a Moss, Norway facility linking engineering, actuator manufacture, robot assembly and testing.
证据范围 · 英文原文
Company-reported manufacturing development in Moss, Norway, announced 2 April 2024. The cited announcement does not establish completion or current operating capacity.
来源
阿拉伯联合酋长国 country:20第20位
贡献
自动驾驶客运服务的应用与运营
入选依据 · 英文原文
The UAE brings external autonomous-driving technology into local transport services. Dubai passenger-operation records support its adoption and operations role.
证据范围 · 英文原文
Dubai RTA’s passenger-service report dated 19 August 2026. Operational figures relate to the service period stated in that report; announced expansion and the 2030 transport target remain prospective.
来源
珠三角核心区(深圳—东莞) cluster:01第1位
贡献
机器人工程、孵化与制造资源对接
入选依据 · 英文原文
Shenzhen and Dongguan connect sensor and robot development with engineering education, prototyping facilities and manufacturing access. XbotPark's university and startup programmes link talent development to product engineering.
证据范围 · 英文原文
Located development and incubation in Shenzhen and Dongguan; named XbotPark startup outcomes and HKUST's April 2026 educational visit. Shenzhen's 2024 academy incubation total covers hardware entrepreneurship. Overseas customers and Hong Kong educational origins retain their locations.
来源
旧金山湾区 cluster:02第2位
贡献
机器人平台、学习研究与共享设施
入选依据 · 英文原文
The Bay Area combines model and robotics-platform development with Berkeley's robot-learning education and Stanford's shared physical research facilities. Reusable software and product companies connect research to physical systems.
证据范围 · 英文原文
Development across San Francisco, San Mateo, Santa Clara and Alameda counties; Berkeley's Spring 2026 course and Stanford Robotics Center's physical research bays. Global platform adoption and site-specific operations retain separate geographic scopes.
来源
长三角核心区(上海—杭州—苏州) cluster:03第3位
贡献
训练基础设施、机器人产品与物理系统研究
入选依据 · 英文原文
The cluster brings Shanghai’s training infrastructure and Hangzhou’s robots and physical-system research into one analytical region, tracing research into product development.
证据范围 · 英文原文
The analytical region covers Shanghai, Hangzhou and Suzhou. Cited robot manufacture, R&D, training and product development are located in Shanghai and Hangzhou; customer sites retain their locations.
来源
北京地区 cluster:04第4位
贡献
机器人学习、驾驶测试与成长型资金
入选依据 · 英文原文
Beijing brings robot-learning resources, developers, district-level driving trials and growth funding into the same regional network.
证据范围 · 英文原文
Located developers, research, driving and delivery activity in Beijing municipality, with operating supervision and external customer locations separately recorded.
来源
首尔首都圈 cluster:05第5位
贡献
楼宇内配送、机器人开发及资本获取
入选依据 · 英文原文
The Seoul Capital Area connects research and manufacturing demand with internal building deliveries and capital-market access.
证据范围 · 英文原文
Seoul, Incheon and Gyeonggi research and development; distinct activities at NAVER 1784 in Seongnam, ROBOTIS in Magok and Doosan in Suwon.
来源
波士顿地区 cluster:06第6位
贡献
硬件初创企业与共享机器人实验
入选依据 · 英文原文
Greater Boston combines robot research, hardware companies and shared experimental space, with documented links to customer logistics.
证据范围 · 英文原文
Greater Boston product development, research and shared experimentation linked to external customer operations; customer sites retain their locations.
来源
匹兹堡地区 cluster:07第7位
贡献
研究成果转化与制造示范
入选依据 · 英文原文
Pittsburgh translates research into company technology transfer and manufacturing demonstrations.
证据范围 · 英文原文
Pittsburgh and Allegheny County research, industrial product development, customer-pilot connections and shared manufacturing resources.
来源
慕尼黑地区 cluster:08第8位
贡献
工业物流集成与增长融资
入选依据 · 英文原文
Munich’s robotics integration companies develop business around industrial customer logistics and growth financing.
证据范围 · 英文原文
Munich city and Landkreis product, integration, research and financing activity; customer plants outside the region retain their locations.
来源
东京—横滨核心区 cluster:09第9位
贡献
机器人控制、集成及测试资源获取
入选依据 · 英文原文
The Tokyo-centered region brings control and robotics companies together with capital and testing access.
证据范围 · 英文原文
Tokyo-centered control, integration and research within the Tokyo-Yokohama-Kawasaki analytical region. Manufacturing and customer events retain their documented city locations.
来源
斯图加特地区 cluster:10第10位
贡献
AI 操控与汽车测试基础设施
入选依据 · 英文原文
Stuttgart brings manufacturing and logistics customers together with AI manipulation and automotive testing requirements.
证据范围 · 英文原文
Region Stuttgart development and shared industrial testing, including Fraunhofer IPA, University of Stuttgart and ARENA2036 facilities; partner facilities retain their own locations.
来源
苏黎世地区 cluster:11第11位
贡献
基于学习机制的检测控制与研究成果商业化
入选依据 · 英文原文
Zurich’s product-development network includes learned control for industrial inspection robots and customer workflows.
证据范围 · 英文原文
Located product development and research-commercialization links, with external inspection sites separately attributed.
来源
新加坡 cluster:12第12位
贡献
面向客户基础设施的机器人集成
入选依据 · 英文原文
Singapore integrates foreign robots into customer infrastructure, with local inspection and operating responsibility.
证据范围 · 英文原文
Located tunnel and retail integration, operator training and research resources; shared country and cluster events are cross-referenced.
来源
欧登塞 cluster:13第13位
贡献
移动机器人与协作机器人开发
入选依据 · 英文原文
Odense provides shared supply and development sites for mobile and collaborative robots.
证据范围 · 英文原文
UR-MiR development infrastructure and DTI equipment, mentoring and incubation in Odense. National industry totals and customer operations retain separate scopes.
来源
西雅图地区 cluster:14第14位
贡献
物流应用企业、无人机工程与机器人数据工具
入选依据 · 英文原文
Seattle’s corporate and development network includes large logistics adopters and robot operating-data tools.
证据范围 · 英文原文
Located drone engineering and manufacture, robot-data work and university research. BRINC's human-piloted missions and Amazon's external operating sites retain their respective attribution.
来源
爱知制造业地区 cluster:15第15位
贡献
制造开发与机器人测试设施
入选依据 · 英文原文
Aichi provides robot testing and support facilities serving manufacturing development.
证据范围 · 英文原文
DENSO WAVE development and manufacture in Agui; Toyota City research and technology transfer. Toyota Motor East Japan customer production retains its external location.
来源
伦敦核心区(剑桥研究与创业渊源) cluster:16第16位
贡献
动作模型、机器人学习与驾驶技术开发
入选依据 · 英文原文
London develops action models, robot learning and vehicle systems toward physical products, with Cambridge represented through its research and founding lineage.
证据范围 · 英文原文
Greater London development and supervised driving trials; joint dexterity research, reusable tools and completed financing. Cambridge retains its distinct lineage role.
来源
滑铁卢核心区 cluster:17第17位
贡献
工业级自主移动机器人(AMR)、自动化集成与服务
入选依据 · 英文原文
The Waterloo core brings industrial AMR products into large-scale automation integration and services.
证据范围 · 英文原文
Kitchener-Waterloo-Cambridge supplier and research ecosystem, including ATS, OTTO, Avidbots, Deep Trekker, RoboHub and SMART Centre.
来源
大田核心区(世宗—五松交通联系) cluster:18第18位
贡献
研发平台、技术转移与演示实验室
入选依据 · 英文原文
Daejeon combines research platforms, technology transfer and robot startups with a physical AI demonstration lab.
证据范围 · 英文原文
Located KAIST and ETRI research, planning and fleet-management transfer. Sejong and Osong retain their transport-link roles and site-specific attribution.
来源
浦项工业机器人与制造研究地区 cluster:19第19位
贡献
机器人制造与钢铁产业发展
入选依据 · 英文原文
Pohang brings a robotics-company site together with a steel customer’s joint laboratory for manufacturing-oriented development.
证据范围 · 英文原文
January 2026 photographed factory visit: Indy and OPTi assembly, actuator and motor production, calibration, aging and precision checks. Located learning-data hardware development and POSTECH research remain separately staged.
来源
奥斯汀地区 cluster:20第20位
贡献
人形机器人开发、客户试用与增长资本
入选依据 · 英文原文
Austin-based Apptronik develops Apollo through Mercedes customer trials and growth financing. The customer trials took place in Germany.
证据范围 · 英文原文
Austin MSA robot development and completed financing linked to Apptronik's Mercedes customer trials in Germany; training and production operation retain their distinct stages.
来源
42dot C001Current 100
贡献
乘车请求与预约
入选依据 · 英文原文
TAP handles ride requests and reservations for the Cheonggyecheon autonomous bus. Government service records describe its platform role alongside 42dot’s technical materials.
证据范围 · 英文原文
2022–2024 TAP service records and platform role; current model technology is documented separately.
来源
AgiBot C002Current 100
贡献
生产线机器人部署
入选依据 · 英文原文
AgiBot G2 was deployed on Longcheer’s tablet production line, as described in the customer’s account of its production process.
证据范围 · 英文原文
Customer and supplier announcements; operating figures are company-reported, and the Q3 figure of 100 robots is a plan.
来源
Agile Robots C003Current 100
贡献
物流自动化集成
入选依据 · 英文原文
Agile Robots brought idealworks into its group through an acquisition, combining robotics development with BMW logistics automation.
证据范围 · 英文原文
Acquisition announcement and BMW logistics application records; subsidiary contributions are recorded at group level.
来源
Agility Robotics C004Current 100
贡献
料箱转运
入选依据 · 英文原文
Digit transfers totes to a conveyor at GXO’s SPANX distribution center. GXO announced the deployment and a multiyear service agreement in 2024.
证据范围 · 英文原文
GXO customer announcement, June 2024: task, deployment and RaaS contract; the robot version in photographs requires separate identification.
来源
AIDIN Robotics N099Current 100
贡献
力传感组件
入选依据 · 英文原文
AIDIN supplies AFT200 force/torque sensing used in demonstration capture and physical Franka manipulation research.
证据范围 · 英文原文
ManipForce v1, III-A and IV-A.2: sensor integration in capture and physical robot execution.
来源
Amazon C005Current 100
贡献
订单履约应用
入选依据 · 英文原文
Amazon deploys, tests and expands robotics within its order-fulfillment operations, acting as the customer responsible for logistics tasks.
证据范围 · 英文原文
Amazon’s account of deployment in operations facilities; company financials cover the whole business.
来源
Ambi Robotics C006Current 100
贡献
物流分拣
入选依据 · 英文原文
AmbiSort applies Sim2Real technology to logistics sorting. Pitney Bowes describes using the system in customer statements published with the product materials.
证据范围 · 英文原文
AmbiSort product documentation and supplier-published Pitney Bowes statements cover existing use and expansion contracts.
来源
AMP Robotics / AMP C007Current 100
贡献
物料分拣
入选依据 · 英文原文
AMP installed and operated neural-network-based material sorting at the Portsmouth facility. Its facility case includes a customer manager’s account of the work.
证据范围 · 英文原文
Supplier facility case and 2025 acquisition announcement; facility throughput and robot-arm performance have distinct scopes.
来源
ANYbotics C008Current 100
贡献
工业检测
入选依据 · 英文原文
ANYmal applies learned control to industrial inspection. ANYbotics describes customer operations using the robots.
证据范围 · 英文原文
Company account of industrial inspection operations; customer counts, reliability and payback figures are company-reported.
来源
Applied Intuition C009Current 100
贡献
车辆仿真与测试
入选依据 · 英文原文
Applied Intuition supplies vehicle simulation and testing software. TRATON confirms their existing collaboration on development tools.
证据范围 · 英文原文
TRATON customer announcement covering five years of tool collaboration; deployment of the new vehicle OS is planned.
来源
Autonomous a2z C010Current 100
贡献
有人监督的载客班车服务
入选依据 · 英文原文
Autonomous a2z’s ROii carried passengers on the Cheonggye A01 shuttle. Seoul’s trial-service notice and a passenger account describe supervised operation.
证据范围 · 英文原文
Seoul trial-service notice and passenger observations; an onboard supervisor can intervene manually.
来源
Baidu C011Current 100
贡献
无人驾驶客运服务
入选依据 · 英文原文
Baidu reports driverless ride activity through Apollo Go. Its contribution is autonomous passenger-service operation.
证据范围 · 英文原文
Issuer operating disclosures; ride counts have a different scope from paid orders, revenue and profitability.
来源
Bedrock Robotics C012Current 100
贡献
自动挖掘
入选依据 · 英文原文
Bedrock retrofits excavators for autonomous digging at named infrastructure customers including Sundt. Its announcement describes sensing, learned models and operation beyond the supervised trial stage.
证据范围 · 英文原文
Bedrock’s deployment announcement describes autonomous digging within supervisor-defined work plans and permitted areas.
来源
Berkshire Grey C013Current 100
贡献
包裹分拣
入选依据 · 英文原文
Berkshire Grey supplies RPSi parcel sorting at FedEx facilities. FedEx describes existing installations and everyday sorting work.
证据范围 · 英文原文
FedEx’s 2022 installation account; later purchase plans and warrant conditions are separate events.
来源
BlackRock C101Current 100
贡献
机器人产业投资基金
入选依据 · 英文原文
BlackRock operates RBOT as an investment route into listed robotics and automation companies.
证据范围 · 英文原文
RBOT fund operation, portfolio holdings and assets under management.
来源
Booster Robotics C015Current 100
贡献
科研与竞赛机器人
入选依据 · 英文原文
Booster supplies K1 and T1 robots used by the HTWK team in research and RoboCup. Team documents describe competition operation and a learned kick executed on T1.
证据范围 · 英文原文
Team documents and joint research; team learning and firmware contributions retain their own attribution.
来源
Boston Dynamics C016Current 100
贡献
挂车卸货
入选依据 · 英文原文
Boston Dynamics supplies robots for commercial trailer unloading at customer sites.
证据范围 · 英文原文
Customer unloading records; the additional commitment of more than 1,000 robots is an MOU, while Atlas development is a separate activity.
来源
Brain Corp C017Current 100
贡献
自主清洁
入选依据 · 英文原文
Brain Corp provides route-learning autonomy for cleaning machines used at Walmart.
证据范围 · 英文原文
Existing customer-use records; the figure of 360 additional machines was a deployment plan.
来源
Built Robotics C018Current 100
贡献
自主太阳能设施建设
入选依据 · 英文原文
Built Robotics completed autonomous solar pile installation with its Gen1 system at a named EPC site.
证据范围 · 英文原文
Project report published through a public agency; evidence concerns the Gen1 deployment and its defined construction task.
来源
Burro C019Current 100
贡献
农场运输
入选依据 · 英文原文
Burro provides autonomous transport at Sierra Gold. A named operations manager describes workers using the robots in nursery tasks.
证据范围 · 英文原文
Burro publishes Sierra Gold’s account of workers using the robots for nursery transport.
来源
Carbon Robotics C020Current 100
贡献
激光除草
入选依据 · 英文原文
Carbon Robotics uses plant recognition to guide LaserWeeder’s laser weeding. Named farms describe using the equipment.
证据范围 · 英文原文
Supplier-published customer testimony; savings and yield effects lack independent verification.
来源
CATL C021Current 100
贡献
制造业应用与电池
入选依据 · 英文原文
CATL describes deploying Galbot S1 on module and battery-pack production lines. Its contribution combines customer adoption with battery supply for robotics.
证据范围 · 英文原文
CATL's announcement describes the system and reports eight-hour operation and battery failure specifications.
来源
Cognex C022Current 100
贡献
工业检测视觉系统
入选依据 · 英文原文
Cognex supplies neural-network-based vision for industrial inspection. Its filings document a perception role within production processes.
证据范围 · 英文原文
Industrial-vision filings. Financial figures cover consolidated GAAP results for FY2025, ending 2025-12-31, in USD millions; machine vision includes rule-based systems and barcode products.
来源
Corvus Robotics C023Current 100
贡献
库存盘点无人机
入选依据 · 英文原文
Corvus supplies inventory drones used at multiple MSI Surfaces warehouse sites.
证据范围 · 英文原文
Supplier account of named-customer use; accuracy and return-on-investment claims are company-reported. MSI Surfaces is the customer.
来源
Coupang C024Current 100
贡献
订单履约作业
入选依据 · 英文原文
Coupang uses people and robots together in fulfillment operations. It represents the customer’s role in deploying automation for order handling.
证据范围 · 英文原文
Operator accounts; overall infrastructure investment has a wider scope than robot purchases, and time-saving figures are party-reported.
来源
Covariant C025Current 100
贡献
学习型拣选
入选依据 · 英文原文
Covariant Brain supports everyday learned picking and sorting at Radial’s TradePort2 facility in Louisville.
证据范围 · 英文原文
Radial’s 2023 customer announcement; throughput and SKU coverage are customer-reported, while later expansion plans are separate.
来源
DeepRobotics C026Current 100
贡献
隧道巡检硬件
入选依据 · 英文原文
DEEP Robotics provides the X30 platform behind SPock power-tunnel patrols. SP Group’s operating account and the integrator’s hardware description identify the customer task and platform.
证据范围 · 英文原文
Customer patrol records and integrator description; feature versions are specific to each deployment.
来源
Dexterity C029Current 100
贡献
挂车装载
入选依据 · 英文原文
Dexterity supplies trailer-loading robotics at FedEx’s Hagerstown hub. The customer describes deployment beyond a pilot.
证据范围 · 英文原文
Joint customer announcement documenting the loading application.
来源
Diligent Robotics C030Current 100
贡献
医院内部配送
入选依据 · 英文原文
Diligent Robotics’ Moxi handles hospital deliveries. CHLA documents repeated deliveries and use by its hospital teams.
证据范围 · 英文原文
Hospital-use records and supplier material; deliveries support hospital logistics. Serve’s separate delivery business retains separate attribution.
来源
DJI C104Current 100
贡献
空中基础设施巡检设备供应
入选依据 · 英文原文
DJI supplies drones used in China Southern Power Grid's route-based inspection. Its later Dock workflow account documents further vendor-reported inspection use in oil and gas.
证据范围 · 英文原文
DJI's named powerline-inspection case dated 2019-05-08; Dock 3 release dated 2025-02-27; unnamed oil/gas operator workflow account dated 2026-02-20, with some AI integrations at experimental stage.
来源
Doosan Robotics C105Current 100
贡献
机器人操作研究平台供应
入选依据 · 英文原文
An external Royal IHC project team used Doosan's 1013 arm in a vision-guided welding prototype. Doosan supplied the manipulation platform; the team developed the vision, integration and welding application.
证据范围 · 英文原文
Smart Manufacturing & Robotics Delft project account published 2025-03-16, covering fall 2023: Doosan 1013, RealSense D415, OpenCV detection and TCP motion commands in a constrained welding prototype.
来源
Dreame Technology C032Current 100
贡献
家居清洁感知能力
入选依据 · 英文原文
Dreame X40 Master performs navigation, obstacle recognition and floor cleaning in a hands-on review that also records recognition errors.
证据范围 · 英文原文
Affiliate-linked product test; Master-specific observations are retained, and borrowed Ultra Complete measurements have separate scope.
来源
Dyna Robotics C033Current 100
贡献
衣物折叠
入选依据 · 英文原文
Dyna Robotics applies robot learning to garment folding at Monster Laundry. The owner describes daily folding work.
证据范围 · 英文原文
Customer quotation; people load and collect garments. Inconsistent time and quantity statements are excluded from performance claims.
来源
Ecovacs C034Current 100
贡献
家居清洁
入选依据 · 英文原文
Ecovacs DEEBOT OZMO T8 AIVI was used in a direct test covering vacuuming, navigation and camera sensing.
证据范围 · 英文原文
RTINGS hands-on test of the base T8 AIVI; mopping was untested in that account, and long-term customer statistics are unavailable.
来源
Elephant Robotics N017Current 100
贡献
教育机器人套件
入选依据 · 英文原文
Elephant Robotics supplies arms and AI kits used in named university teaching and physical student projects.
证据范围 · 英文原文
Undated supplier university cases documenting adopted educational platforms and student-developed tasks.
来源
Farm-ng N020Current 100
贡献
农业开发平台
入选依据 · 英文原文
Farm-ng supplies Amiga as an adopted agricultural education platform in the recurring Farm Robotics Challenge, including CMU's seedling-planting project; university teams retain attachments and task development.
证据范围 · 英文原文
UC ANR account, 2025-05-08: third annual Farm Robotics Challenge, Amiga educational-platform use and CMU's physical seedling-planting project.
来源
Field AI C035Current 100
贡献
施工巡检自主控制
入选依据 · 英文原文
Field AI provides autonomy for Spot-based inspection at changing construction sites. Its account describes perception, mapping and use by site managers.
证据范围 · 英文原文
Field AI describes a deployment at an unnamed construction customer, covering perception, mapping and inspection.
来源
Figure AI C036Current 100
贡献
人形机器人工厂试点应用
入选依据 · 英文原文
Figure 02 handled sheet-metal parts during BMW's extended Spartanburg production pilot.
证据范围 · 英文原文
BMW report, 2026-02-27, pp. 4-5: ten-month pilot with weekday production shifts.
来源
Flexiv C037Current 100
贡献
力控食品加工
入选依据 · 英文原文
Flexiv’s delivered Rizon 4 solution locates fish fillets on a moving conveyor and shapes them using force control.
证据范围 · 英文原文
Supplier case for a specific delivered application; the customer is unnamed and independent acceptance and performance tests are unavailable.
来源
Formic C038Current 100
贡献
包装与码垛服务
入选依据 · 英文原文
Formic supplies vision-based packaging and palletizing as a service. Its product account includes customers describing active production use.
证据范围 · 英文原文
Supplier-published customer statements; installed software versions, uptime and commercial terms require deployment-specific evidence.
来源
ForwardX Robotics C039Current 100
贡献
仓库拣选辅助
入选依据 · 英文原文
ForwardX Flex assists picking in Li & Fung’s IKEA e-commerce warehouse. Its product materials describe visual perception and movement responses.
证据范围 · 英文原文
Supplier customer case and product-family technical material; performance and feature versions are supplier-reported.
来源
Foxglove C040Current 100
贡献
机器人日志分析
入选依据 · 英文原文
Foxglove provides development and operating-log tools used by Square Robot for field analysis.
证据范围 · 英文原文
Named-customer tool-use record; the contribution concerns software analysis, while the customer retains responsibility for robot operations.
来源
Galbot C041Current 100
贡献
生产线机器人供应
入选依据 · 英文原文
Galbot S1 works on CATL module and battery-pack lines. CATL describes deployment, visual positioning and obstacle avoidance.
证据范围 · 英文原文
CATL customer announcement; evidence concerns S1 production-line use, with future staffing and service-standard plans recorded separately.
来源
Gaussian Robotics / Gausium C043Current 100
贡献
门店清洁
入选依据 · 英文原文
Gausium supplies cleaning robots adopted at named ELVI stores.
证据范围 · 英文原文
Customer article republished by the supplier; subsequent investment is recorded as planned.
来源
Geek+ C045Current 100
贡献
仓储搬运
入选依据 · 英文原文
Geek+ provides warehouse movement within projects documented by implementation participants. People retain the picking role in the integrated workflow.
证据范围 · 英文原文
Implementation participants describe the warehouse project and the division between robot movement and human picking.
来源
GelSight C046Current 100
贡献
触觉研究设备
入选依据 · 英文原文
GelSight supplies the Mini sensor used by Politecnico di Milano researchers to acquire tactile measurements on industrial components with a FANUC collaborative robot. The researchers retain the anomaly-detection methods and evaluation.
证据范围 · 英文原文
Research v1, 2026-08-31, sections 3.3 and 4: adopted Mini instrumentation for robot-mounted dataset acquisition and external inspection-method comparison.
来源
GXO C047Current 100
贡献
客户物流集成
入选依据 · 英文原文
GXO operates Digit at its SPANX site, integrating tote transfers with existing mobile robots and conveyors under a multiyear RaaS agreement.
证据范围 · 英文原文
GXO customer announcement; contract price, cash flows, residual value and measured uptime are undisclosed in the record.
来源
HAI Robotics C048Current 100
贡献
仓储机器人系统
入选依据 · 英文原文
HAI Robotics supplies ACR and AMR warehouse systems, including a Hyundai Mobis application.
证据范围 · 英文原文
Hai Robotics' Hyundai Mobis case describes tote retrieval and parts transport at the Suwon High Tech Center's spare-parts warehouse. Picking workstations retain the human picking step. This record recognizes the warehouse-system contribution described in that case.
来源
HaptX N030Current 100
贡献
触觉遥操作
入选依据 · 英文原文
HaptX supplies tactile gloves adopted in Sanctuary's development workflow, providing human teleoperation input.
证据范围 · 英文原文
Sanctuary customer account and HaptX robotics cases, undated: gloves used in the customer's pilot-rig teleoperation workflow; autonomous robot tasks remain development.
来源
Hesai C049Current 100
贡献
激光雷达(LiDAR)组件
入选依据 · 英文原文
Hesai’s Pandar sensors are used on WeRide vehicles. Supplier materials include the customer’s account of sensor adoption.
证据范围 · 英文原文
Supplier-published customer statement; evidence identifies a sensing component within the vehicle system.
来源
Horizon Robotics C050Current 100
贡献
驾驶辅助计算
入选依据 · 英文原文
Horizon Robotics supplies Journey6M computing for NOA features in delivered customer vehicles.
证据范围 · 英文原文
Driver-assistance supply records; Journey 6M delivery and the planned 6H deployment retain their distinct product stages.
来源
Hyundai Motor Group C051Current 100
贡献
战略性机器人业务股权
入选依据 · 英文原文
Hyundai Motor Group completed its controlling investment in Boston Dynamics in 2021. The joint announcement recorded an 80% group stake at closing.
证据范围 · 英文原文
2021 transaction announcement; the stake belongs to the group-level transaction, and current ownership requires separate evidence.
来源
InOrbit C052Current 100
贡献
机器人运营工具
入选依据 · 英文原文
InOrbit supports monitoring and remote exception management for Kärcher KIRA B50 cleaning robots.
证据范围 · 英文原文
Customer statement and RobOps case; operations include remote support, with autonomy and certification assessed at the robot-system level.
来源
Intuitive Surgical C053Current 100
贡献
机器人辅助支气管镜检查
入选依据 · 英文原文
Intuitive Surgical’s Ion supports shape-sensing catheter manipulation for bronchoscopy and biopsy. North Tees describes trial adoption and actual biopsies in 2025.
证据范围 · 英文原文
Hospital account documenting physician-assisted use of the specified system version in the reported cases.
来源
JLG — Canvas Robotics N037Current 100
贡献
建筑机器人技术转让
入选依据 · 英文原文
JLG acquired Canvas core technology and integrated its team, carrying forward construction-robotics capabilities through a completed technology transfer.
证据范围 · 英文原文
JLG January 2026 announcement: technology acquisition and team integration; further integrated solutions are planned.
来源
John Deere C054Current 100
贡献
选择性喷洒
入选依据 · 英文原文
John Deere’s See & Spray recognizes plants and applies selective spraying in customer fields. Its commercial approach includes performance-linked charging.
证据范围 · 英文原文
Supplier savings claims and sponsored research; evidence is specific to the cited fields and billing arrangement.
来源
Keenon Robotics C055Current 100
贡献
餐厅与酒店服务机器人
入选依据 · 英文原文
Keenon’s DINERBOT and cleaning systems perform transport and service tasks at named restaurants and hotels, with staff handoffs and obstacle avoidance.
证据范围 · 英文原文
Supplier-published customer statements; newer humanoid demonstrations are separate development records.
来源
Kodiak Robotics / Kodiak AI C057Current 100
贡献
越野运输
入选依据 · 英文原文
Kodiak supplies customer-owned trucks for limited off-road transport at Atlas.
证据范围 · 英文原文
Supplier delivery and transport reports; evidence covers the off-road domain and its stated operating scope.
来源
Locus Robotics C058Current 100
贡献
拣选辅助
入选依据 · 英文原文
Locus robots assist human picking across multiple customer sites with repeated tasks.
证据范围 · 英文原文
Customer-use records; cumulative task totals have a different scope from profitability, failure rates and unattended operation.
来源
Meituan C061Current 100
贡献
自动配送运营
入选依据 · 英文原文
Meituan operates drone and ground delivery systems. Its technical account connects sensing and autonomous movement with actual delivery orders.
证据范围 · 英文原文
Company operating totals; drone and ground-vehicle periods and denominators remain separate.
来源
Mobile Industrial Robots / MiR C062Current 100
贡献
AMR 容器运输
入选依据 · 英文原文
MiR250 transports KLT containers at BORG Automotive, with MES completion confirmation. Customer and integrator statements describe the workflow.
证据范围 · 英文原文
Supplier-published interviews; MiR hardware, Octant integration and customer picking retain separate contributions.
来源
Momenta C063Current 100
贡献
量产级驾驶智能
入选依据 · 英文原文
Momenta supplies driving intelligence for named production customers including SAIC IM and Lynk.
证据范围 · 英文原文
Production-customer records covering L2 to L2++ functions; planned L3 and L4 functions are separate.
来源
Mytra C064Current 100
贡献
库存缓冲与排序
入选依据 · 英文原文
Mytra supports inventory buffering and sequencing before shipment at selected Albertsons distribution centers.
证据范围 · 英文原文
Mytra publishes Albertsons staff statements about inventory buffering and sequencing at selected distribution centers.
来源
NAVER / NAVER LABS C065Current 100
贡献
建筑集成式机器人运营
入选依据 · 英文原文
NAVER and NAVER LABS operate repeated internal deliveries at 1784, integrating robots with the building and elevators.
证据范围 · 英文原文
Internal customer-operation records; the parent and development subsidiary share one activity record, with external sales assessed separately.
来源
Nearthlab C066Current 100
贡献
风力涡轮机检测
入选依据 · 英文原文
Nearthlab’s NearthWind performs autonomous wind-turbine blade inspection. Its materials describe sensing, flight and inspection contracts with Siemens Gamesa, Vestas and GE.
证据范围 · 英文原文
Supplier contract history and cumulative totals; inspection volumes and safety records are company-reported.
来源
Nimble Robotics N053Current 100
贡献
机器人履约服务供应
入选依据 · 英文原文
Nimble supplies robotic fulfillment used by named brands for picking, packing and shipping; later alliance plans extend that operating contribution.
证据范围 · 英文原文
Supplier customer cases including Fresh Clean Threads' 2023 fulfillment; FedEx alliance announcement, 2024-09-05.
来源
NVIDIA C067Current 100
贡献
机器人开发基础设施
入选依据 · 英文原文
NVIDIA’s Isaac Sim, Isaac Lab and GR00T support robot simulation, learning and deployment. Its May 2025 announcement names platform users including Agility, Boston Dynamics and Galbot.
证据范围 · 英文原文
Platform-use announcement; financial figures are company-wide consolidated GAAP for FY2026 ending 2026-01-25, in USD millions. The release tables are marked unaudited; user-site effects require user-specific evidence.
来源
Orbbec C068Current 100
贡献
深度感知
入选依据 · 英文原文
Orbbec’s Gemini 336L supplies RGB and depth streams for Quasi Model C2. A customer engineer describes SDK integration into Q.AI.
证据范围 · 英文原文
Supplier-published customer statement; sensor supply and Quasi’s mapping, planning and control retain separate attribution.
来源
OrionStar C069Current 100
贡献
工厂工序间物料搬运
入选依据 · 英文原文
OrionStar CarryBot transports materials between processes at a Yanai Denki factory in Japan.
证据范围 · 英文原文
2025 company-republished newspaper account of deployment; newspaper text and fleet-wide outcomes lack separate verification.
来源
OSARO C070Current 100
贡献
基于学习技术的包装作业
入选依据 · 英文原文
OSARO provides learned vision and control for Zenni packaging, with later records describing transition into production.
证据范围 · 英文原文
OSARO’s records distinguish the 2022 packaging plan from the subsequent production transition at Zenni.
来源
Parallel Domain C071Current 100
贡献
合成感知数据
入选依据 · 英文原文
Parallel Domain supplies synthetic perception-training data used by named organizations including Google, Woven and Toyota Research Institute.
证据范围 · 英文原文
Supplier customer-use claims; cited abstracts provide limited independent attribution of the particular dataset.
来源
Path Robotics C072Current 100
贡献
机器人焊接
入选依据 · 英文原文
Path Robotics supplies a welding cell used by Millerbernd to fabricate transport and infrastructure poles. The case includes a welder describing the work.
证据范围 · 英文原文
Supplier case and worker quotation describing the welding application.
来源
Pickle Robot C073Current 100
贡献
挂车卸货
入选依据 · 英文原文
Pickle Robot unloads UPS trailers using motion and path selection in actual handling work.
证据范围 · 英文原文
Supplier-published customer quotation; the cited 90-minute task is distinct from a shift-average measure.
来源
Plus One Robotics C074Current 100
贡献
包裹视觉识别与异常处理
入选依据 · 英文原文
Plus One’s PickOne provides vision recognition for FedEx parcel sorting, while Yonder supports remote exception handling.
证据范围 · 英文原文
The FedEx site record describes Plus One’s vision and remote exception handling alongside Yaskawa’s arm, gripper and integration.
来源
Pudu Robotics C075Current 100
贡献
办公室清洁
入选依据 · 英文原文
PUDU CC1 Pro cleans carpets and floors in shared areas of a Walmart US office facility, using navigation and path planning.
证据范围 · 英文原文
Supplier case covering office common areas; publication date and independent labor-saving logs are unavailable.
来源
Quicktron C076Current 100
贡献
仓库货架搬运
入选依据 · 英文原文
Quicktron M-Series moves shelves in Coupang’s goods-to-person workflow. RCS and higher-level systems allocate warehouse tasks.
证据范围 · 英文原文
Supplier case; people perform final picking, and fleet counts and efficiency figures are company-reported.
来源
RightHand Robotics C078Current 100
贡献
仓库拣选
入选依据 · 英文原文
RightPick performs picking at apo.com and PALTAC. Named customer statements describe operating use and learning features.
证据范围 · 英文原文
Supplier-published statements; storage and transport by AutoStore or Murata have separate roles, while order totals cover the wider workflow.
来源
Roborock C079Current 100
贡献
物体拾取与清洁
入选依据 · 英文原文
Roborock Saros Z70 recognizes and picks up a limited range of objects while cleaning. A purchaser’s test records both use and failures.
证据范围 · 英文原文
Qualitative hands-on review; observations include automatic and manual operation, with no formal success-rate measurement.
来源
ROBOTIS C080Current 100
贡献
研究用执行器与平台
入选依据 · 英文原文
ROBOTIS supplies actuators and physical platforms used in research and education, including dual-arm learning work.
证据范围 · 英文原文
Supplier index and user research paper; evidence covers component use in research, with commercial returns assessed separately.
来源
Roboto AI C081Current 100
贡献
机器人运行分析
入选依据 · 英文原文
Roboto AI supports post-flight QA for BRINC and robot-fault analysis for ANYbotics. Named customer staff describe using the tools.
证据范围 · 英文原文
Supplier-published customer statements; time-saving claims lack independent audit, and the contribution concerns data analysis.
来源
Robust.AI C082Current 100
贡献
协作式料箱运输
入选依据 · 英文原文
Robust.AI’s Carter transports totes and assists picking at Saddle Creek’s Charlotte site. A named operations manager describes its use.
证据范围 · 英文原文
Supplier-published customer statements; announced charging policies and productivity claims have separate financial and measurement scopes.
来源
Rockwell Automation C083Current 100
贡献
MES 与 AMR 集成
入选依据 · 英文原文
Rockwell integrates MES with OTTO transport at its Twinsburg factory, dispatching moves from production orders.
证据范围 · 英文原文
Internal factory-use case; dispatch is rule-based, and cost-recovery figures are company calculations.
来源
Saildrone C084Current 100
贡献
海洋观测
入选依据 · 英文原文
Saildrone performs repeated ocean-observation missions for NOAA, transmitting measurements used in public scientific datasets.
证据范围 · 英文原文
NOAA multi-year mission records; navigation autonomy operates with a defined supervision scope, while scientific analysis has separate attribution.
来源
Samsung Electronics C085Current 100
贡献
战略性机器人股权收购
入选依据 · 英文原文
Samsung’s filings document acquisition of control over Rainbow Robotics and its consolidation into the group.
证据范围 · 英文原文
Financial filings on strategic ownership; payments for existing shares are distinct from new cash raised by Rainbow.
来源
Sarcos → Palladyne AI C086Current 100
贡献
维护自动化软件
入选依据 · 英文原文
Palladyne AI supplies learned software for automated surface preparation at Warner Robins. A named customer describes completion of the first contract phase.
证据范围 · 英文原文
Supplier-published customer statement; the second phase was planned, and the four-year contract amount is distinct from cash received.
来源
Seoul Robotics C087Current 100
贡献
工厂车辆感知
入选依据 · 英文原文
Seoul Robotics supplies external perception for vehicle movement inside a BMW factory.
证据范围 · 英文原文
BMW customer material; partner systems handle driving plans, steering and braking within the factory domain.
来源
Shadow Robot N072Current 100
贡献
灵巧型研究用机械手供应
入选依据 · 英文原文
Shadow Robot co-developed DEX-EE hardware with DeepMind and supplies the released standard research hand used in DeepMind's DemoStart experiments. Hardware development and supply retain joint credit; DeepMind retains its learning method.
证据范围 · 英文原文
Shadow account, 2024-06-06: standard build available to the market; DeepMind account, 2024-09-12: adopted DEX-EE hardware in physical manipulation research.
来源
SoftBank C090Current 100
贡献
仓储自动化股权与投资载体
入选依据 · 英文原文
SoftBank completed a secondary Symbotic share purchase and established the GreenBox joint-venture vehicle for warehouse automation.
证据范围 · 英文原文
Joint announcement, 2023-07-24: completed ownership transaction and established vehicle; initial funding and multiyear purchases are commitments.
来源
Standard Robots C091Current 100
贡献
AMR 托盘搬运
入选依据 · 英文原文
Standard Robots supplies AMRs used to transport pallets at TRUSCO’s Planet Saitama logistics center.
证据范围 · 英文原文
TRUSCO customer announcement; evidence concerns the deployed transport system, while newer VLA features have separate scope.
来源
Superbin C092Current 100
贡献
AI 回收收集
入选依据 · 英文原文
Superbin’s Nephron uses AI classification in installed recycling-collection units.
证据范围 · 英文原文
Installation and maintenance history; repeated references to the same 100-unit event count as one event.
来源
Symbotic C093Current 100
贡献
物流自动化系统
入选依据 · 英文原文
Symbotic supplies logistics automation systems documented in filings alongside customer contracts.
证据范围 · 英文原文
Operating systems and contractual commitments have separate status; the 400-system figure is a conditional purchase commitment.
来源
Syrius Robotics / Syrius Technology C094Current 100
贡献
拣选辅助型自主移动机器人 (AMR)
入选依据 · 英文原文
Syrius provides picking-assistance AMRs through Syrius Japan and ROBOCREW at STOCKCREW. The customer announced completed trials and full deployment beginning in 2022.
证据范围 · 英文原文
Customer’s 2022 announcement; people perform picking. Supplier fleet and five-year contract figures have separate verification status.
来源
UBTECH C103Current 100
贡献
工业人形机器人供应及工厂作业任务
入选依据 · 英文原文
UBTECH reports industrial humanoid production and delivery for automotive-factory handling, sorting and inspection. Its selected contribution is the supply of robots for those tasks.
证据范围 · 英文原文
UBTECH 2025 results filed with HKEX on 2026-03-31, printed pp. 2-4 and 10-11; supplier industrial application page describing named-factory tasks, accessed October 2026.
来源
Unitree Robotics C095Current 100
贡献
实体机器人研究平台
入选依据 · 英文原文
Unitree supplies physical robots used in external whole-body motion research.
证据范围 · 英文原文
External research preprint; evidence concerns physical-platform use in research.
来源
Universal Robots C096Current 100
贡献
温室采摘硬件
入选依据 · 英文原文
Universal Robots supplies UR5e arms used by eternal.ag for greenhouse harvesting. The case includes the customer CTO’s account.
证据范围 · 英文原文
Supplier-published customer case; AI-model development, crop yield and long-term operating economics have distinct attribution.
来源
Viam C097Current 100
贡献
机器人机群运营软件
入选依据 · 英文原文
Viam provides fleet data, status checks and code deployment for Tennibot. Named customer leaders describe practical use.
证据范围 · 英文原文
Supplier-published customer case; further AI integration was planned, while fleet support capacity differs from actual deployment.
来源
VisionNav Robotics C098Current 100
贡献
自动叉车物流
入选依据 · 英文原文
VisionNav VNL16 transports materials through inbound, shelving and outbound workflows for an equipment manufacturer, following scans and RCS instructions.
证据范围 · 英文原文
VisionNav describes an unnamed manufacturer’s inbound, shelving and outbound workflow. Continuous operation is a stated target.
来源
Waymo C102Current 100
贡献
无人驾驶客运服务运营
入选依据 · 英文原文
Waymo operates rider-only passenger services across multiple US regions. Its operating disclosure and California deployment-permit record identify autonomous passenger-service operation.
证据范围 · 英文原文
Waymo operating data through June 2026; CPUC deployment-permit table accessed October 2026; manufacturer recall 25E-034 filed with NHTSA on 2025-05-12.
来源
XYZ Robotics C099Current 100
贡献
仓库卸货设备供应
入选依据 · 英文原文
XYZ Robotics supplied RockyOne for unloading at Nitori Home Logistics' Satte site, with the supplier reporting stable operational pilots and announcing expansion.
证据范围 · 英文原文
Supplier account, 2026-02-16: Satte pilots began June 2025; regional expansion is prospective; Japanese distribution begins February 2026.
来源
Zipline C100Current 100
贡献
自主空中配送
入选依据 · 英文原文
Zipline performs paid autonomous aerial deliveries with sensing and flight functions documented in its operating accounts.
证据范围 · 英文原文
Company reports; delivery counts, item counts and distance use separate units, while future regions and platforms retain planned status.
来源
1X Technologies N001Next 100
贡献
全身策略学习
入选依据 · 英文原文
1X’s Redwood describes a policy that learns locomotion and manipulation together. NEO’s ordering and support terms provide a separate product-development record.
证据范围 · 英文原文
Company model and product materials; ordering, planned shipment, delivery and repeated household use are distinct stages, with external voice processing and remote support recorded separately.
来源
AeiROBOT N100Next 100
贡献
研究与竞赛平台
入选依据 · 英文原文
AeiROBOT and HERoEHS jointly develop ALICE4 walking and competition vision within their humanoid research programme.
证据范围 · 英文原文
HERoEHS 2025 team description, pp. 1-2: completed walking/vision work and proposed controller upgrades.
来源
Aeva N002Next 100
贡献
工业传感
入选依据 · 英文原文
Aeva’s Eve sensing technology is integrated into a SICK sensor product described in a launch announcement.
证据范围 · 英文原文
Aeva’s product announcement describes Eve sensing integrated into a SICK sensor.
来源
Aigen N003Next 100
贡献
农业实地试验
入选依据 · 英文原文
Aigen’s Element began use at the named Bowles farm. Customer quotations describe early evaluation in the field.
证据范围 · 英文原文
Supplier-published customer account of initial trials; operating hours, intervention and herbicide-cost comparisons are company claims.
来源
Alibaba N004Next 100
贡献
机器人感知与动作模型
入选依据 · 英文原文
Alibaba’s RynnBrain release provides model and code resources, with VLA transfer reported on G1, Astribot and Tianji-Wuji platforms.
证据范围 · 英文原文
RynnBrain’s official repository provides model and code resources, with authors reporting physical tests on specified robots.
来源
Ambarella N005Next 100
贡献
机器人推理集成开发
入选依据 · 英文原文
Ambarella supplies CV72 inference computing for e-con's ROS 2 rover demonstration of object search, approach, alignment and imaging. The partners' selected robotics integration remains a development contribution.
证据范围 · 英文原文
e-con engineering account, May 2026: CES 2025 physical rover demonstration using CV72eSOM, ROS 2 and Nav2; perception/navigation integration validation.
来源
Anthropic N006Next 100
贡献
语言模型控制研究
入选依据 · 英文原文
Anthropic tested Claude on robotics control tasks using MuJoCo and LIBERO. Its published research records model calls, simulation conditions and failures.
证据范围 · 英文原文
Anthropic’s published robotics research covers model-driven control in specified simulated tasks, including recorded failures.
来源
Apple N007Next 100
贡献
机器人交互与学习数据
入选依据 · 英文原文
Apple’s ARMADA research collects manipulation trajectories with AR feedback and replays them on physical robots. ELEGNT adds research on expressive robot movement.
证据范围 · 英文原文
Joint research involving 15 participants and three ARMADA tasks; evidence covers interaction and data-development experiments.
来源
Apptronik N008Next 100
贡献
人形机器人客户试用
入选依据 · 英文原文
Apptronik develops Apollo for repetitive manufacturing tasks through Mercedes' production-environment data collection and employee teleoperation-based training.
证据范围 · 英文原文
Mercedes customer account, 2025-03-18: integration testing, training data and autonomous-development step.
来源
Astribot N009Next 100
贡献
操作策略研究
入选依据 · 英文原文
Astribot’s Lumo-1 paper describes S1 learning and physical pick-and-place tests.
证据范围 · 英文原文
The Lumo-1 paper describes S1 learning and its physical pick-and-place test conditions.
来源
Autodesk N010Next 100
贡献
学习型装配
入选依据 · 英文原文
Autodesk combines planning and reinforcement learning in physical dual-arm assembly research.
证据范围 · 英文原文
Joint university research reports physical dual-arm assembly; completed steps and completed products use distinct success measures.
来源
BeingBeyond N011Next 100
贡献
基于视频的机器人学习
入选依据 · 英文原文
BeingBeyond trains robot behavior from human video. Being-H0.5 reports tests on five robot platforms, and its repository provides an SO101 deployment procedure.
证据范围 · 英文原文
Author-reported research and repository documentation; video-derived pseudo-tactile signals and physical tactile measurements have different scopes.
来源
BeyondHoneycomb N012Next 100
贡献
烹饪状态感知
入选依据 · 英文原文
BeyondHoneycomb develops cooking systems that use AI and sensors to measure and reproduce cooking states.
证据范围 · 英文原文
Investor D2SF describes the cooking system’s AI and sensor development. Customer references are anonymous.
来源
bitsensing N013Next 100
贡献
雷达穿梭巴士试点
入选依据 · 英文原文
bitsensing’s pilot material describes an actual road shuttle at FIX 2025.
证据范围 · 英文原文
The official pilot account describes a road shuttle at FIX 2025; the 500-vehicle figure is an expansion plan.
来源
Black Sesame N101Next 100
贡献
机器人计算套件
入选依据 · 英文原文
Black Sesame reports initial supply of its Aura development kit, extending automotive computing toward robotics development.
证据范围 · 英文原文
Black Sesame announces initial Aura development-kit supply. The record concerns developer hardware rather than final AUBO customer deployment.
来源
ByteDance N014Next 100
贡献
机器人动作模型研究
入选依据 · 英文原文
ByteDance’s GR-2 research combines video pretraining with robot trajectories and manipulation tests.
证据范围 · 英文原文
Paper abstract and limited affiliation records; reported tests concern research, with the later GR3 page excluded from detailed evidence.
来源
Config N015Next 100
贡献
机器人数据与任务模型
入选依据 · 英文原文
Config publishes HABIT robot observation and action data, supporting its reported CFG-1 learning and physical-task development.
证据范围 · 英文原文
Company and repository documentation for HABIT and CFG-1. Timing figures are reported by Config.
来源
DEEPX N016Next 100
贡献
机器人边缘计算
入选依据 · 英文原文
DEEPX develops robotics inference computing with Hyundai Motor Group’s Robotics Lab. Hyundai material connects earlier edge-brain work with DAL-e demonstrations, while DX-M2 defines a further development path.
证据范围 · 英文原文
Joint-development and demonstration records; earlier edge-brain results and DX-M2 completion, production supply and customer revenue have separate status. This is the Korean DEEPX company.
来源
EngineAI N018Next 100
贡献
学习与部署工具
入选依据 · 英文原文
EngineAI publishes PM01 reinforcement-learning training, simulation validation and physical deployment procedures.
证据范围 · 英文原文
PM01 repository documentation covers training, simulation validation and hardware deployment procedures, using Isaac Lab infrastructure.
来源
Faraday Dynamics N019Next 100
贡献
机器人执行器
入选依据 · 英文原文
Faraday Dynamics develops Direct Drive and QDD actuator components, with sample fabrication and trial-production history described in an event profile.
证据范围 · 英文原文
An event profile records the Korean actuator company’s sample fabrication and trial-production history.
来源
Flexion Robotics N104Next 100
贡献
全身任务策略
入选依据 · 英文原文
Flexion’s June 2026 Reflect v1.0 report describes a humanoid retrieving a parcel, navigating between floors and interacting with doors and elevators. Learned motion policies and whole-body control connect those steps into a research demonstration.
证据范围 · 英文原文
Company-reported Reflect v1.0 research demonstration, published 29 June 2026; the entry covers the documented missions and controller. Customer acceptance and safety certification are outside this report’s evidence.
来源
Flexxbotics N021Next 100
贡献
检测与返工流程的集成
入选依据 · 英文原文
Flexxbotics describes integration that turns inspection results into robot rework and equipment correction.
证据范围 · 英文原文
Supplier implementation materials describe statistical process control and machine-learning functions separately.
来源
Floatic N022Next 100
贡献
协作拣选试验
入选依据 · 英文原文
Floatic tested collaborative picking with LogisALL at a named location, documenting the robot, software and human work roles.
证据范围 · 英文原文
Floatic’s company account covers a LogisALL picking proof of concept with specified robots, software and human roles.
来源
Fourier Intelligence N023Next 100
贡献
机器人训练与部署工具
入选依据 · 英文原文
Fourier publishes GRx code connecting reinforcement-learning training, MuJoCo validation and physical-robot deployment.
证据范围 · 英文原文
Fourier’s GRx README and code describe a research-platform workflow from training through simulation to hardware deployment.
来源
Galaxea AI N024Next 100
贡献
物理操作学习
入选依据 · 英文原文
Galaxea’s research connects data collection on a specified robot with policy learning and four physical-task evaluations.
证据范围 · 英文原文
Galaxea’s research team reports policy learning and four physical-task evaluations on specified hardware.
来源
Gecko Robotics C044Next 100
贡献
机器人辅助零部件检测
入选依据 · 英文原文
Gecko develops robotic inspection and AI analysis for a new forged-component workflow with BPMI and suppliers.
证据范围 · 英文原文
Gecko announcement, 2025-07-15: initial component-inspection trials and proposed digital-thread expansion.
来源
Generalist AI N025Next 100
贡献
操作模型研究
入选依据 · 英文原文
Generalist’s GEN-0 materials describe robot-specific manipulation tests and model structure.
证据范围 · 英文原文
Company research account describing the model and reporting its training-data hours.
来源
Genesis AI N026Next 100
贡献
物理操作开发
入选依据 · 英文原文
Genesis AI describes GENE-26.5 physical manipulation demonstrations and its data and hand architecture.
证据范围 · 英文原文
Genesis AI’s release describes physical research demonstrations and data and hand architecture; Eno customer deployment is planned.
来源
Genisom AI N027Next 100
贡献
机器人软件开发工具
入选依据 · 英文原文
Genisom provides development documentation connecting VLMs, LLMs, MATRiX and ROS2 with execution procedures.
证据范围 · 英文原文
Official linked repository; visual navigation reaches simulation instructions, and hardware deployment is marked TODO.
来源
Gole Robotics N028Next 100
贡献
建筑运输试验
入选依据 · 英文原文
Gole Robotics tested material transport at a named construction site.
证据范围 · 英文原文
The recorded construction field trial concerns robot transport of materials at a named site.
来源
Google DeepMind N029Next 100
贡献
端侧机器人模型
入选依据 · 英文原文
Google DeepMind’s Gemini Robotics On-Device combines a local model, SDK and physical adaptation tests.
证据范围 · 英文原文
The Gemini Robotics On-Device release covers a local model, SDK and physical adaptation tests under stated research conditions.
来源
Hello Robot N111Next 100
贡献
开放词汇移动操作开发
入选依据 · 英文原文
Hello Robot maintains the developing Stretch AI integration for language-directed mobile manipulation, connecting semantic memory, navigation and task execution. Its team reports physical pick-and-place demonstrations; inherited Meta HomeRobot and other research methods retain their original attribution.
证据范围 · 英文原文
Hello Robot repository and documentation, accessed 2026-10-11: developer-reported physical language-directed pick-and-place and experimental code-policy, semantic-memory and navigation integration. The networked GPU configuration uses calibrated hardware; DynaMem also documents a reduced-capability onboard CPU mode.
来源
Helm.ai N031Next 100
贡献
驾驶模型开发
入选依据 · 英文原文
Helm.ai develops driving models under a collaboration whose scope and application pathway are confirmed by a named OEM.
证据范围 · 英文原文
Customer-confirmed development agreement; mass production, payments and L3 approvals have separate status.
来源
Hexagon N032Next 100
贡献
人形机器人训练与验证
入选依据 · 英文原文
Hexagon’s AEON entered Schaeffler’s Humanoid Gym for training and validation.
证据范围 · 英文原文
Hexagon describes AEON training and validation at Schaeffler’s Humanoid Gym. The 1,000-robot figure is a future deployment plan.
来源
Honda N033Next 100
贡献
灵巧的遥操作辅助
入选依据 · 英文原文
Honda describes a dexterous hand using intent estimation and contact feedback, including repeated learning of screwdriver regrasping.
证据范围 · 英文原文
Honda technical research account; teleoperation and AI assistance are distinct functions, and measured figures are company-reported.
来源
Hugging Face N113Next 100
贡献
紧凑型“感知到动作”模型研究
入选依据 · 英文原文
Hugging Face co-develops SmolVLA, connecting visual observations and instructions to manipulation actions. Its research evaluates SO100 and SO101 physical tasks, with shared credit for academic partners, hardware designers and community data contributors.
证据范围 · 英文原文
June 2025 research and released model resources: physical manipulation evaluations and task adaptation. LeRobot's separately adopted infrastructure is recognized in I026; this company entry selects SmolVLA model research.
来源
Intel N034Next 100
贡献
神经形态机器人控制研究
入选依据 · 英文原文
Intel contributes Loihi 2 computing to joint NRL/Intel research converting a reinforcement-learning controller into neuromorphic inference for Astrobee simulation.
证据范围 · 英文原文
Joint NRL/Intel research v1, 2025-12-03: chip-executed inference and closed-loop Astrobee simulation; feasibility validation.
来源
Intrinsic N035Next 100
贡献
AI 制造集成
入选依据 · 英文原文
Intrinsic integrates perception and path planning into TRUMPF’s SortMaster Vision development.
证据范围 · 英文原文
TRUMPF SortMaster Vision product integration; the record covers development and software integration.
来源
JD.com N036Next 100
贡献
多源动作学习
入选依据 · 英文原文
JD.com’s JoyAI-RA research describes learning from multiple data sources and evaluation in simulation and physical benchmarks.
证据范围 · 英文原文
Research-team materials and paper abstract describing the action model.
来源
KNOWIN N039Next 100
贡献
闭环策略研究
入选依据 · 英文原文
KNOWIN’s GLOW report describes a model and real-robot one-shot and closed-loop evaluations.
证据范围 · 英文原文
Author-reported physical evaluations; simulation and scene-question-answering results retain their separate test scopes.
来源
Leju Robotics N040Next 100
贡献
机器人开发工具
入选依据 · 英文原文
Leju’s LeTools provides public code and a documented route to physical-robot deployment.
证据范围 · 英文原文
LeTools’ official README describes public code and hardware deployment procedures. Factory agreements are separate corporate records.
来源
LG Electronics N041Next 100
贡献
家庭操作任务开发
入选依据 · 英文原文
LG’s CLOiD development combines VLM and VLA systems with a wheeled, dual-arm structure for household tasks and appliance integration.
证据范围 · 英文原文
LG’s CES announcement and preview describe CLOiD household-task development and demonstration plans.
来源
LimX Dynamics N042Next 100
贡献
硬件联动开发工具
入选依据 · 英文原文
LimX publishes development tools and robot-specific execution procedures for hardware-linked engineering. In a separate humanoid navigation demonstration, RealSense supplies RGB-D camera input, NVIDIA supplies cuVSLAM odometry and LimX integrates the navigation system.
证据范围 · 英文原文
LimX's public materials describe hardware-linked development and execution procedures; speed figures are supplier-reported. The undated RealSense account documents camera input in a physical humanoid demonstration. RealSense retains supplier credit outside the 200-company selection.
来源
Lumos Robotics N043Next 100
贡献
操作任务数据平台
入选依据 · 英文原文
Lumos provides FastUMI data-platform code and a physical policy-development path for Touch R1.
证据范围 · 英文原文
FastUMI repository and Touch R1 documentation cover data and policy-development tools. The JD agreement is a separate partnership event.
来源
Machina Labs N044Next 100
贡献
闭环成形技术
入选依据 · 英文原文
Machina Labs combines closed-loop forming with scan-based correction, including a Toyota demonstration pathway.
证据范围 · 英文原文
Machina Labs describes closed-loop forming, scan correction and a Toyota demonstration. Published depth specifications conflict between 4 ft and 5 ft.
来源
MakinaRocks N045Next 100
贡献
机器人维护模型
入选依据 · 英文原文
MakinaRocks develops maintenance models for HD Hyundai Samho welding robots, using simulated-fault tests described in its September 2026 technical account.
证据范围 · 英文原文
The September 2026 technical report covers maintenance-model development and simulated faults on HD Hyundai Samho welding robots.
来源
Maven Robotics N102Next 100
贡献
物流部署开发
入选依据 · 英文原文
Maven Robotics describes a product launch and deployment for specific logistics tasks.
证据范围 · 英文原文
Maven’s company announcement describes product release and logistics deployment at an unnamed customer. Accumulated operating hours are a target.
来源
Mentee Robotics / Mentee by Mobileye N046Next 100
贡献
物理操作学习
入选依据 · 英文原文
Mentee describes observation, offline reinforcement learning and physical execution for battery replacement and handing over cans.
证据范围 · 英文原文
Company physical-development account; customer trials, success denominators and independent verification remain unavailable.
来源
Meta N047Next 100
贡献
协作机器人基准测试
入选依据 · 英文原文
Meta publishes PARTNR data and benchmarks, with research describing application to Spot and tests of collaboration, failure and recovery.
证据范围 · 英文原文
Company research release covering the specified tools and research tests.
来源
Microsoft N048Next 100
贡献
机器人规划与动作模型
入选依据 · 英文原文
Microsoft’s Magma repository provides robot-planning demonstrations, training code, model releases and evaluation procedures.
证据范围 · 英文原文
Magma’s official repository and joint research provide planning demonstrations, training code and evaluation procedures.
来源
Mobilint N096Next 100
贡献
机器人策略编码器集成研究
入选依据 · 英文原文
Mobilint supplies Aries2 hardware for an external study of robot-policy encoder offloading, retaining hardware credit separately from the researchers' policy and evaluation.
证据范围 · 英文原文
Research v1, 2026-08-15: physical Aries2 encoder inference, GPU action computation and simulated rollouts; energy, latency and task-success trade-offs.
来源
Mobiltech N097Next 100
贡献
空间数据资产
入选依据 · 英文原文
Mobiltech supplies documented 3D spatial assets and links them to named test grounds and simulators.
证据范围 · 英文原文
Mobiltech's published simulation and open-data asset records describe the spatial-data contribution.
来源
MORAI N049Next 100
贡献
驾驶仿真工具
入选依据 · 英文原文
MORAI publishes sensor models, path-generation documentation and driving examples for autonomous-driving development.
证据范围 · 英文原文
MORAI’s documentation and public repository cover driving-simulation sensor models, path generation and examples.
来源
Near Earth Autonomy N051Next 100
贡献
自主飞行器系统集成
入选依据 · 英文原文
Near Earth Autonomy reports autonomous AW139 flight and RUC60 integration development.
证据范围 · 英文原文
Company records describe AW139 autonomous flight tests and RUC60 integration development.
来源
NEURA Robotics N052Next 100
贡献
机器人学习平台
入选依据 · 英文原文
NEURA describes robots, a learning platform and a joint welding application with Abicor Binzel.
证据范围 · 英文原文
NEURA’s Automatica announcement covers robots, learning infrastructure and a joint welding application. Production-scale goals remain targets.
来源
Noetix Robotics N054Next 100
贡献
强化学习工具
入选依据 · 英文原文
Noetix publishes N2 reinforcement-learning code, model export and sim-to-sim procedures.
证据范围 · 英文原文
Noetix’s N2 README provides reinforcement-learning, export and sim-to-sim procedures for research development.
来源
Nota AI N095Next 100
贡献
机器人推理运行时
入选依据 · 英文原文
Nota’s NQRR runtime operated on a Qualcomm board with SO-101 in a color-based cube-transfer demonstration at KRAIN 2026.
证据范围 · 英文原文
Official technical report of a demonstration; further integration validation remains planned, and general semiconductor contracts retain their own scope.
来源
Nuro N055Next 100
贡献
Robotaxi 员工试运行
入选依据 · 英文原文
Nuro’s driving system entered employee ride tests confirmed by Uber, extending its development path beyond delivery vehicles.
证据范围 · 英文原文
Partner-confirmed employee trials; Lucid vehicle supply, Uber operation and Nuro control retain separate roles.
来源
Outrider N056Next 100
贡献
自动堆场作业试验
入选依据 · 英文原文
Outrider’s 2024 material describes customer-site movement trials and deep-learning-based connection tasks.
证据范围 · 英文原文
Outrider’s 2024 account describes customer-site trials and learned connection tasks. Customer identities are undisclosed.
来源
PaXini N057Next 100
贡献
触觉操控
入选依据 · 英文原文
PaXini describes tactile-feedback control for DexH13 grasping and handle manipulation, and TORA-ONE cup and wafer tasks.
证据范围 · 英文原文
PaXini’s reports cover physical tactile-control demonstrations; data production capacity and cloud access are announced plans.
来源
Persona AI N058Next 100
贡献
遥操作焊接
入选依据 · 英文原文
Persona AI demonstrated physical movement, posture and arc welding at ARC Specialties using teleoperation.
证据范围 · 英文原文
Persona AI’s report describes teleoperated movement, posture and arc welding at ARC Specialties.
来源
Physical Intelligence N059Next 100
贡献
开放式策略开发工具
入选依据 · 英文原文
Physical Intelligence’s openpi provides models, checkpoints and documented inference and fine-tuning procedures.
证据范围 · 英文原文
The openpi README provides models, checkpoints, inference and fine-tuning instructions as public development resources.
来源
Qualcomm N060Next 100
贡献
机器人计算环境
入选依据 · 英文原文
Qualcomm provides robotics evaluation boards, ROS 2 and Gazebo samples, with a documented separation of perception and control.
证据范围 · 英文原文
Official developer documentation; compute specifications and actual robot-task performance have separate measurement scopes.
来源
Raion Robotics N061Next 100
贡献
四足机器人控制开发
入选依据 · 英文原文
Raion Robotics records a long-distance mobility test in its company history and describes quadruped-control development.
证据范围 · 英文原文
Raion’s company history describes a long-distance quadruped mobility test and control-development work.
来源
RealMan N062Next 100
贡献
机器人数据与遥操作
入选依据 · 英文原文
RealMan describes physical platforms, teleoperation and data QA for RealBot and Darwin development, alongside a data center it reports as operating.
证据范围 · 英文原文
RealMan describes robot development, teleoperation and data QA, with center scale and operating status reported by the company.
来源
Realtime Robotics N064Next 100
贡献
运动规划优化
入选依据 · 英文原文
Realtime Robotics applied motion-planning tools in a Volkswagen cell proof of concept and described resulting adjustments.
证据范围 · 英文原文
Supplier proof-of-concept account; evidence concerns automatic path search and collision avoidance, with learning-model attribution excluded.
来源
Reliable Robotics N065Next 100
贡献
机载探测与避障研究
入选依据 · 英文原文
Reliable Robotics tested sensor tracking and ACAS-Xr alerts in actual flight for detect-and-avoid development.
证据范围 · 英文原文
Reliable-authored report hosted by the FAA; the system had no flight-control authority, and 52 of 56 refers to achieved encounter conditions.
来源
Rhoda AI N109Next 100
贡献
基于视频预训练的工业操作研究
入选依据 · 英文原文
Rhoda tests how web-video pretraining affects robot-policy performance in industrial bearing unpacking. Its physical evaluation connects model choices to a defined multistep handling task.
证据范围 · 英文原文
Rhoda research account dated 2026-09-10: bearing-unpacking robot-policy study, task scoring and recorded physical trials; development evaluation in a customer task setting.
来源
Richtech Robotics N066Next 100
贡献
AI 饮料操作
入选依据 · 英文原文
Richtech’s ADAM uses vision and control AI to observe drinks and adjust movement and pouring, as described in its FY2025 filing and later development announcement.
证据范围 · 英文原文
Richtech’s FY2025 filing and 2026 announcement describe ADAM perception and pouring development. Feature claims retain their stated periods.
来源
RIVR N110Next 100
贡献
地形感知包裹递送试验
入选依据 · 英文原文
RIVR develops wheeled-legged robots for parcel delivery with Veho. The customer's initial field experiment tests stairs, gates and uneven sidewalks while staff accompany the robot and collect learning data.
证据范围 · 英文原文
Veho customer account, 2025-05-27: accompanied last-meter parcel-delivery experiment; Veho 2026 innovation account reports the launch of RIVR robots.
来源
RLWRLD N067Next 100
贡献
物理操作策略研究
入选依据 · 英文原文
RLWRLD’s paper describes physical ALLEX and Franka tasks with specified evaluation criteria.
证据范围 · 英文原文
RLWRLD’s paper reports ALLEX and Franka research tasks; 86.8% is the research team’s average for its specified tasks.
来源
RoboForce N105Next 100
贡献
工业机器人试点项目
入选依据 · 英文原文
RoboForce develops TITAN and reports ongoing pilots for robot tasks in demanding industrial environments.
证据范围 · 英文原文
Company announcements documenting prototype development, pilot activity and contract signing as separate milestones.
来源
RobotEra N068Next 100
贡献
预测性操作策略开发
入选依据 · 英文原文
RobotEra develops the VPP predictive-visual manipulation-policy programme and supplies XHand used in external LeVR experiments. Hardware supply and each research team's policy retain separate attribution.
证据范围 · 英文原文
RobotEra VPP repository and LeVR v1, 2025-09-17: policy development and real-robot manipulation evaluation with Franka FER and XHand.
来源
ROBROS N069Next 100
贡献
基于学习的积木分拣
入选依据 · 英文原文
ROBROS demonstrated learned block sorting on physical hardware.
证据范围 · 英文原文
The physical demonstration covers learned block sorting; service rollout is a target. ROBROS and ROBOTIS are separate companies.
来源
Sanctuary AI N070Next 100
贡献
接触式任务学习
入选依据 · 英文原文
Sanctuary describes learned physical contact tasks on FR3.
证据范围 · 英文原文
Research-development evidence; the FR3 results and Phoenix factory work are separate activities, while the Magna agreement retains agreement status.
来源
Saronic N071Next 100
贡献
自主水面船舶试验
入选依据 · 英文原文
Saronic’s Corsair completed multi-day trials described as funded by the company’s own research and development budget.
证据范围 · 英文原文
Company account of the reported vessel trials. Marauder is a separate development programme.
来源
Siemens C088Next 100
贡献
工厂集成试验
入选依据 · 英文原文
Siemens develops control and integration for Humanoid's HMND01 Alpha tote-handling trials at its Erlangen factory.
证据范围 · 英文原文
Joint announcement, 2026-04-16: factory validation and trial performance targets.
来源
Skild AI N073Next 100
贡献
多机器人操作
入选依据 · 英文原文
Skild develops robot manipulation through tests and partner pilots. Zebra announced the sale of its Robotics Automation business to Skild in April 2026.
证据范围 · 英文原文
Company and transaction announcements; Fetch records provide historical business context, and reported deployment and ARR lack independent verification.
来源
Sony N074Next 100
贡献
工具使用学习
入选依据 · 英文原文
Sony and Edinburgh researchers trained a physical Franka robot to use tools from a small number of demonstrations.
证据范围 · 英文原文
Joint research report; evidence concerns physical experiments, with commercial robot sales and household deployment outside that scope.
来源
Spirit AI N075Next 100
贡献
物理环境下的策略部署支持
入选依据 · 英文原文
Spirit provides documentation for fine-tuning PI05 and deploying inference on a physical Moz robot.
证据范围 · 英文原文
Spirit’s support documentation describes PI05 fine-tuning and inference on Moz. Source access requires a support key.
来源
Standard Bots N103Next 100
贡献
机器人开发与教育
入选依据 · 英文原文
Standard Bots combines physical robots with development and education packages, extending its equipment offering toward learning from demonstrations.
证据范围 · 英文原文
Standard Bots provides physical robots with development and education packages. It is separate from Standard Robots in China.
来源
Sunday N076Next 100
贡献
家用机器人开发
入选依据 · 英文原文
Sunday describes kitchen and household-task development with specific technical stages and a late-2026 beta plan.
证据范围 · 英文原文
Sunday describes household-task development and a beta planned for late 2026.
来源
TARS Robotics N078Next 100
贡献
操作数据与开发套件
入选依据 · 英文原文
TARS provides devkits and data repositories supporting WIYH physical-manipulation learning.
证据范围 · 英文原文
WIYH paper, devkit and repository documentation. Chronology follows the cited paper's publication record.
来源
Tencent N079Next 100
贡献
机器人平台集成
入选依据 · 英文原文
Tencent’s platform describes model and RoboFusion components used in a Unitree G1 trial at Dunhuang’s digital exhibition center.
证据范围 · 英文原文
Official platform account of the pilot, with hardware contributions by Unitree and EngineAI.
来源
Tesla N080Next 100
贡献
人形机器人生产准备
入选依据 · 英文原文
Tesla’s Q2 2026 materials describe Optimus production-line installation, training-data collection and autonomy-compute infrastructure.
证据范围 · 英文原文
Company production-preparation records; installation, production completion and customer acceptance have separate status.
来源
Torc Robotics N108Next 100
贡献
高速公路自动驾驶货运验证
入选依据 · 英文原文
Torc validates a highway-freight driving system using production-intent hardware in driver-out closed-course tests. Its public-road testing and commercial-launch target describe a continuing development programme.
证据范围 · 英文原文
Torc validation announcement, 2024-10-29: driver-out multilane closed-course testing; live FAQ accessed October 2026: public-road safety drivers and planned 2027 commercialization.
来源
Toyota Motor Corporation / Toyota Research Institute N107Next 100
贡献
全身操作策略开发
入选依据 · 英文原文
Toyota Research Institute jointly develops language-conditioned large behavior models with Boston Dynamics. The partners connect teleoperated training data to physical Atlas manipulation and recovery tests.
证据范围 · 英文原文
Boston Dynamics joint technical account, accessed October 2026: real-robot and simulated data collection, policy training, and Atlas workshop manipulation evaluation.
来源
Vayu Robotics N081Next 100
贡献
基于学习的配送移动能力
入选依据 · 英文原文
Vayu’s 2024 announcement describes a physical delivery robot combining transformer-based movement with passive optical sensors, plus application to wheeled platforms.
证据范围 · 英文原文
Company development report and announcement of a 2,500-unit deployment contract.
来源
Vention N082Next 100
贡献
工业感知工具
入选依据 · 英文原文
Vention provides the GRIIP SDK and describes RapidOperator AI handling object variation and retrying failed tasks.
证据范围 · 英文原文
Vention’s documentation describes SDK-based perception and retry handling, using NVIDIA development infrastructure.
来源
Vueron N083Next 100
贡献
道路感知试验
入选依据 · 英文原文
Vueron describes road tests with defined US routes and safety-driver conditions, alongside a documented 2021 Korean trial.
证据范围 · 英文原文
Vueron’s test material specifies road routes and safety-driver conditions, including a documented Korean trial in 2021.
来源
Waabi N084Next 100
贡献
自动驾驶卡车集成
入选依据 · 英文原文
Waabi completed integration with a truck platform confirmed by the OEM, taking its simulation-based model toward physical deployment.
证据范围 · 英文原文
The OEM announcement confirms Waabi integration with a physical truck platform.
来源
Wayve N112Next 100
贡献
基于语言的驾驶控制研究
入选依据 · 英文原文
Wayve's LINGO-2 research model jointly predicts driving trajectories and commentary, with a closed-loop Central London public-road demonstration. Separate Ghost Gym trials compare manoeuvres under different language prompts; explanation/action alignment and reliable real-world language control remain research questions.
证据范围 · 英文原文
Wayve, 2024-04-17, LINGO-2 architecture and research demonstrations: public-road trajectory execution with commentary in Central London; language-conditioned manoeuvre comparisons in Ghost Gym simulation; open alignment and real-world language-control research.
来源
WIRobotics N085Next 100
贡献
机器人研究模型
入选依据 · 英文原文
WIRobotics publishes MJCF, URDF and USD models, replay examples and evaluation procedures for its v2 research prototype.
证据范围 · 英文原文
WIRobotics releases research models and replay tools. USD support is experimental, Gazebo is unsupported and mesh use is restricted to evaluation.
来源
Wonik Robotics N086Next 100
贡献
具备感知能力的机器人手
入选依据 · 英文原文
Wonik’s Allegro V6 F adds contact sensing and a control interface, extending its hand platform for learning-data development.
证据范围 · 英文原文
Wonik’s September 2026 release specifies V6 F contact sensing and control interfaces; investment funding is described as planned.
来源
World Labs N087Next 100
贡献
生成式机器人仿真开发
入选依据 · 英文原文
World Labs supplies Marble-generated worlds for two named researchers' robotics simulation experiments, with exported scenes and manually added task assets.
证据范围 · 英文原文
World Labs case, 2025-11-12: exploratory MuJoCo/RoboSuite and Isaac Sim workflows; generated scenes and task-development experiments.
来源
X Square Robot N088Next 100
贡献
策略训练工具
入选依据 · 英文原文
X Square provides a documented LeRobot integration with training and deployment procedures.
证据范围 · 英文原文
Official LeRobot guidance describes X Square’s policy training and deployment integration, separate from Galaxea’s G0 hardware.
来源
Xiaomi N089Next 100
贡献
物理动作模型研究
入选依据 · 英文原文
Xiaomi publishes model and code paths for physical tasks including LEGO disassembly and towel folding.
证据范围 · 英文原文
Physical manipulation experiments, including LEGO disassembly and towel folding, with published model and code resources.
来源
Xingyuanzhi N092Next 100
贡献
机器人感知与动作开发
入选依据 · 英文原文
Xingyuanzhi describes RoboBrain Pro, a jointly developed EP loading and unloading product, robot integration and physical cleaning work.
证据范围 · 英文原文
Company history and product material; customer-scale and team-background statements have separate evidence scope.
来源
XPENG Robotics / IRON N090Next 100
贡献
人形机器人硬件开发
入选依据 · 英文原文
XPENG describes IRON’s physical autonomous walking, onboard model and production-line development.
证据范围 · 英文原文
XPENG’s announcement describes physical walking and onboard-model development; 2027 deliveries are planned.
来源
Yuequan Bionic N093Next 100
贡献
仿生手原型
入选依据 · 英文原文
Yuequan Bionic’s hand prototype performed movements observed in an exhibition report.
证据范围 · 英文原文
The exhibition account describes a hand prototype performing remote movement imitation without naming its exact model.
来源
Abhinav Gupta P001Influence 50
贡献
语义导航研究
入选依据 · 英文原文
Abhinav Gupta co-developed SemExp, separating semantic goal selection from path planning in robot navigation.
证据范围 · 英文原文
CMU’s account and the research abstract identify Gupta’s joint SemExp contribution.
来源
Anca Dragan P002Influence 50
贡献
意图感知运动规划
入选依据 · 英文原文
Anca Dragan’s dissertation incorporates an observer’s inference of intent into motion planning and evaluates physical collaboration.
证据范围 · 英文原文
Dragan’s dissertation records intent-aware planning and joint physical-collaboration research.
来源
Andrea Thomaz P003Influence 50
贡献
医院配送产品策略
入选依据 · 英文原文
Andrea Thomaz explains choosing interdepartmental item delivery as the hospital robot’s product task.
证据范围 · 英文原文
Founder interview describing the contribution, with Vivian Chu and the product team sharing the work.
来源
Brett Adcock P043Influence 50
贡献
人形机器人产业策略
入选依据 · 英文原文
Brett Adcock’s named plan chose manufacturing and logistics as early humanoid applications, emphasizing repetitive work in human environments.
证据范围 · 英文原文
Public strategic plan; BMW negotiations, Helix design and commercial returns have separate attribution.
来源
Chelsea Finn E006Influence 50
贡献
机器人控制策略研究与训练
入选依据 · 英文原文
Chelsea Finn contributed policy training and research to pi0.5.
证据范围 · 英文原文
The joint paper's Appendix A-A names Finn under policy training and research. MAML authorship and public-code reuse are separately documented contributions.
来源
Chen Jianyu P004Influence 50
贡献
机器人研究通讯作者
入选依据 · 英文原文
Jianyu Chen is the corresponding author of DWL, contributing to its joint research publication.
证据范围 · 英文原文
Paper author information; Gu, Wang, Zhu and Shi retain their stated equal project-lead contributions.
来源
Cheon Hong-seok P048Influence 50
贡献
机器人业务共同经营
入选依据 · 英文原文
Cheon Hong-seok describes product launches, initial fundraising and donations to medical institutions in a joint interview with Cheon Yeong-seok.
证据范围 · 英文原文
Government-supported program interview; evidence concerns shared management choices and their stated execution.
来源
Chris Urmson P005Influence 50
贡献
无人驾驶货运运营决策
入选依据 · 英文原文
In May 2025, Chris Urmson explained Aurora’s decision to move an observer to the front seat at vehicle partner PACCAR’s request. Aurora said the observer would not drive.
证据范围 · 英文原文
Aurora statement dated 16 May 2025, describing a partner-requested seating change. The observer’s non-driving role is Aurora’s account, not an independent operational finding.
来源
Deepak Pathak P007Influence 50
贡献
自适应行走研究
入选依据 · 英文原文
Deepak Pathak co-developed Rapid Motor Adaptation with Ashish Kumar, Zipeng Fu and Jitendra Malik.
证据范围 · 英文原文
CMU attributes RMA co-development to Pathak and collaborators in physical adaptive-walking research.
来源
Ding Han P029Influence 50
贡献
机器人表面加工领域的领导工作
入选依据 · 英文原文
Ding Han led a project on robotic machining of large complex surfaces, with documented joint development and industrial application pathways.
证据范围 · 英文原文
University report covering eight institutions and 30 researchers; application and performance claims are institution-reported.
来源
Euisun Chung P008Influence 50
贡献
战略性股权参与
入选依据 · 英文原文
Euisun Chung participated as a distinct party in the Boston Dynamics ownership and share-subscription agreement alongside Hyundai affiliates.
证据范围 · 英文原文
SoftBank’s 2020 agreement announcement; valuation and combined ownership have separate scope from personal payments and completed funding.
来源
Hang Zhao P034Influence 50
贡献
基础模型研究的领导角色
入选依据 · 英文原文
Hang Zhao co-led foundation-model research with Huazhe Xu.
证据范围 · 英文原文
University account and profile; the role is joint research leadership, with company revenues and model-wide results separately attributed.
来源
Hod Lipson P011Influence 50
贡献
机器人自建模研究
入选依据 · 英文原文
Hod Lipson contributed to research conception, analysis support and review of robot self-modeling work.
证据范围 · 英文原文
Published contribution statement; Hu and Lin retain their specified method, software, analysis and drafting roles.
来源
Huang Xiaoqing P050Influence 50
贡献
云机器人控制研究
入选依据 · 英文原文
Huang Xiaoqing co-authored research describing HARI and Igor and their implementations.
证据范围 · 英文原文
Named joint authorship; individual technical divisions are unpublished, while company-wide results retain organizational attribution.
来源
Hyoun Jin Kim P040Influence 50
贡献
空中操作研究
入选依据 · 英文原文
Hyoun Jin Kim contributed to aerial-manipulation research that demonstrated physical door opening.
证据范围 · 英文原文
Seoul National University's account identifies Kim's joint aerial-manipulation research and the team's physical door-opening demonstration without assigning individual control-design components.
来源
In So Kweon P038Influence 50
贡献
DRC-HUBO 联合研究领导工作
入选依据 · 英文原文
In So Kweon co-led Team KAIST with Jun-Ho Oh and Rainbow researchers at the 2015 DARPA Robotics Challenge. Their DRC-HUBO robot completed the competition’s eight tasks and won the finals.
证据范围 · 英文原文
KAIST’s June 2015 competition report identifies shared team leadership and the completed course. It attributes the result to the team rather than assigning individual vision or depth algorithms to Kweon.
来源
Jaeheung Park P042Influence 50
贡献
平衡控制研究
入选依据 · 英文原文
Jaeheung Park co-authored CP-MPC balance-control research reporting physical and simulated validation.
证据范围 · 英文原文
Paper authorship and abstract identify Park’s joint CP-MPC balance-control research.
来源
Jeff Cardenas P012Influence 50
贡献
工业市场进入策略
入选依据 · 英文原文
Jeff Cardenas describes a funding strategy focused on development and early entry into industrial customer applications.
证据范围 · 英文原文
Founder interview and reporting on shared business decisions; technical design, contract terms and cash recovery have separate attribution.
来源
Jemin Hwangbo P049Influence 50
贡献
“仿真到现实”(Sim-to-real)控制研究
入选依据 · 英文原文
Jemin Hwangbo contributed ideas, learned control and simulation design in joint sim-to-real research.
证据范围 · 英文原文
Published contribution table; experiments are shared and the recovery policy is attributed to J.L., with later Korean commercial use assessed separately.
来源
黄仁勋 / Jensen Huang P013Influence 50
贡献
机器人平台策略
入选依据 · 英文原文
Jensen Huang presented the public platform direction and releases of GR00T, Cosmos and Isaac.
证据范围 · 英文原文
Public strategy and launch statements; NVIDIA engineers and robot manufacturers retain model, SDK and integration contributions.
来源
Jonathan Hurst P014Influence 50
贡献
双足机器人硬件设计
入选依据 · 英文原文
Jonathan Hurst explains Cassie’s design choices, including changes to motor interaction, steering, feet and enclosure compared with ATRIAS.
证据范围 · 英文原文
Designer explanation and university account; co-founders and university teams retain joint hardware and control contributions.
来源
Ken Goldberg P016Influence 50
贡献
学习型抓取研究
入选依据 · 英文原文
Ken Goldberg co-created Dex-Net with Jeff Mahler, providing a shared research output for learned grasping.
证据范围 · 英文原文
Official project attribution, with AUTOLAB and the paper's co-authors sharing the research contribution.
来源
Kim Yong-jae P039Influence 50
贡献
轻量级辅助机器人研究
入选依据 · 英文原文
Kim Yong-jae’s university profile connects clutch and lightweight-design research with WIRobotics product development.
证据范围 · 英文原文
University profile and company co-founding history, with Lee Yeon-baek and the research teams sharing the work.
来源
Kyoungchul Kong P037Influence 50
贡献
辅助机器人团队领导工作
入选依据 · 英文原文
Kyoungchul Kong led a Cybathlon team developing and executing assistive-robot tasks.
证据范围 · 英文原文
Personal CV; Kim Seung-hwan was the pilot, while the engineering team retains shared development credit.
来源
Kyu-Jin Cho P047Influence 50
贡献
变刚度机器人设计
入选依据 · 英文原文
Kyu-Jin Cho served as corresponding author on a folding drone arm and explained its variable-stiffness design.
证据范围 · 英文原文
Joint research and Cho’s design explanation concern the folding robotic arm, with named co-authors retaining their roles.
来源
Leng Xiaokun P041Influence 50
贡献
人形机器人研究资金投入策略
入选依据 · 英文原文
Leng Xiaokun describes reinvesting income from smaller products into large-robot research.
证据范围 · 英文原文
Interview published by his university; evidence concerns a funding choice, with company-wide technology and delivery results separately attributed.
来源
Linxi “Jim” Fan P017Influence 50
贡献
奖励生成(Reward-generation)研究
入选依据 · 英文原文
Jim Fan co-led Eureka and served as corresponding author on research generating and optimizing reward code for robot learning.
证据范围 · 英文原文
Joint research with Anima Anandkumar and collaborators; the reported 29-environment evaluation is simulation-based.
来源
Marc Raibert P018Influence 50
贡献
动态行走研究
入选依据 · 英文原文
Marc Raibert pioneered and led research in dynamic legged locomotion.
证据范围 · 英文原文
Documented historical contribution; later Atlas decisions retain team-level attribution.
来源
Masayoshi Son P019Influence 50
贡献
战略交易决策
入选依据 · 英文原文
Masayoshi Son and Yoshimitsu Goto received delegated authority to determine the final terms of SoftBank’s ABB Robotics acquisition agreement. The board resolution and October 2025 agreement document his role in that capital decision.
证据范围 · 英文原文
SoftBank's October 2025 acquisition agreement, subject to closing conditions, and the board's delegation of final terms-setting authority.
来源
Melonee Wise P020Influence 50
贡献
产品与工程组织架构
入选依据 · 英文原文
Melonee Wise describes building and reorganizing Agility’s engineering and product teams, alongside technology-roadmap work at Zebra.
证据范围 · 英文原文
Personal 2025 résumé and 2022 employer statement; evidence concerns historical responsibilities rather than a verified current position.
来源
Nick Paine P021Influence 50
贡献
执行器设计与控制
入选依据 · 英文原文
Nick Paine’s dissertation documents UT-SEA design and control research, including application of some control methods to Valkyrie.
证据范围 · 英文原文
Named dissertation abstract describing the specified technical work.
来源
Nikita Rudin P051Influence 50
贡献
大规模并行运动训练研究
入选依据 · 英文原文
Nikita Rudin co-authored a massively parallel locomotion-training approach and curriculum evaluated on ANYmal and transferred to a physical robot.
证据范围 · 英文原文
Joint research with David Hoeller, Philipp Reist and Marco Hutter; repository records separately document public code and outside reuse.
来源
Oh Jun Ho E019Influence 50
贡献
DRC-HUBO 联合研究领导工作
入选依据 · 英文原文
Oh Jun Ho co-led Team KAIST with In So Kweon and Rainbow researchers in the 2015 DARPA Robotics Challenge.
证据范围 · 英文原文
KAIST documents joint team leadership and competition task completion, alongside HUBO platform development and use by outside research teams.
来源
Oussama Khatib P022Influence 50
贡献
水下遥操作研究
入选依据 · 英文原文
Oussama Khatib led OceanOne research and contributed to a remotely operated underwater recovery task.
证据范围 · 英文原文
2016 human-teleoperation case; subsequent OceanOneK work and commercial results have separate scope.
来源
Park Jong Hoon P023Influence 50
贡献
垂直整合战略
入选依据 · 英文原文
Park Jong Hoon describes choosing vertical integration after encountering limits in demand.
证据范围 · 英文原文
Interview republished by the company; design, manufacturing and solution teams share product-execution credit.
来源
Peng Zhihui P024Influence 50
贡献
机器人产品开发领导工作
入选依据 · 英文原文
Peng Zhihui led X-Lab development associated with the 2025 X2 release.
证据范围 · 英文原文
An event-organizer profile identifies Peng’s joint development leadership on X2.
来源
Qiao Hong P030Influence 50
贡献
机器人控制方法研究
入选依据 · 英文原文
Qiao Hong proposed an environment-attractor-region method explicitly attributed to her by CAS.
证据范围 · 英文原文
CAS’s profile attributes the method proposal to Qiao; team members retain application and implementation contributions.
来源
Richie Chen P035Influence 50
贡献
ACR 联合开发
入选依据 · 英文原文
Richie Chen participated with Shengdong Xu and Bing Fang in developing ACR after warehouse visits.
证据范围 · 英文原文
The official white paper describes joint ACR development by Richie Chen, Shengdong Xu and Bing Fang.
来源
Rodney Brooks P025Influence 50
贡献
分层机器人控制
入选依据 · 英文原文
Rodney Brooks proposed layered robot control in an authored paper. Later researchers explicitly implemented the method.
证据范围 · 英文原文
Historical original research and subsequent paper; reported simulations and industrial deployments retain distinct status.
来源
Rolf Dieter Schraft E021Influence 50
贡献
机器人编程方法研究
入选依据 · 英文原文
Rolf Dieter Schraft co-authored robot-programming and trajectory-adaptation research with C. Meyer for a gluing robot cell.
证据范围 · 英文原文
The official 2006 abstract describes geometric trajectory primitives and a triangulation-based trajectory metric for robot programming.
来源
Sabine Hauert P026Influence 50
贡献
群集控制研究的领导工作
入选依据 · 英文原文
Sabine Hauert co-directed research on explainable swarm control.
证据范围 · 英文原文
Joint research and experiments; the university account places field application at a later stage.
来源
Seok Sang-ok P044Influence 50
贡献
集成机器人服务策略
入选依据 · 英文原文
Seok Sang-ok presented a direction for shared human-robot spaces and integrated services in 2019, later reflected in NAVER 1784’s operating pathway.
证据范围 · 英文原文
Public strategy and subsequent team-operation accounts; development, architecture, cloud and service implementation retain shared credit.
来源
Sergey Levine P027Influence 50
贡献
基于学习的视觉反馈研究
入选依据 · 英文原文
Sergey Levine co-authored learned visual-feedback grasping research and explained its use of large-scale physical interaction in a signed Google research article.
证据范围 · 英文原文
Joint research with Pastor, Krizhevsky and Quillen, accompanied by Levine’s signed explanation of the research approach.
来源
Wang Hesheng P033Influence 50
贡献
联合感知研究
入选依据 · 英文原文
Wang Hesheng served as corresponding author and co-author of FlowDet-Track.
证据范围 · 英文原文
FlowDet-Track author information identifies Wang’s corresponding-author and joint-publication roles.
来源
Wang Tianran E033Influence 50
贡献
工业机器人产品开发领导工作
入选依据 · 英文原文
Wang Tianran led historical integration of team-developed controllers with purchased robot bodies and pursued factory applications.
证据范围 · 英文原文
SIA's retrospective attributes product-development and market-entry decisions to Wang and reports applications at Shenyang Jinbei Seat Factory and Anshan Excavator Factory; controller teams and later Siasun contributors share credit.
来源
Wang Xingxing P028Influence 50
贡献
四足机器人设计与控制
入选依据 · 英文原文
Wang Xingxing designed XDog and held development responsibility for a quadruped group-control system.
证据范围 · 英文原文
Shanghai University alumni account; team development and later Unitree business results retain separate attribution.
来源
Wang Yaonan P032Influence 50
贡献
工业检测项目负责人
入选依据 · 英文原文
Wang Yaonan led a pharmaceutical robotic visual-inspection and control project documented by Hunan University.
证据范围 · 英文原文
2019 institutional account, with researchers, equipment makers and application companies sharing the contribution.
来源
Zhao Mingguo E034Influence 50
贡献
人形机器人足球联合研究负责人
入选依据 · 英文原文
Zhao Mingguo's team developed vision-driven reactive soccer research; Zhao served as corresponding author and Wang Yushi as first author.
证据范围 · 英文原文
Tsinghua reports physical Booster T1 tasks and competition use, crediting student researchers, partner institutions, hardware and test-site support.
来源
Zhou Jian P046Influence 50
贡献
人形机器人研究投资
入选依据 · 英文原文
Zhou Jian decided to fund and continue large-humanoid research in 2015 despite internal objections, according to a retrospective account.
证据范围 · 英文原文
A retrospective article attributes a 2015 humanoid research-funding decision to Zhou.
来源
Zhu Qiuguo P031Influence 50
贡献
四足机器人稳定性控制研究
入选依据 · 英文原文
Zhu Qiuguo held a principal research role in dynamic stability control for the Jueying quadruped.
证据范围 · 英文原文
2019 university research announcement; later DEEP Robotics operations and customer outcomes have separate scope.
来源
Aaron Ames E001Ecosystem Builders 50
贡献
共享步态规划工具
入选依据 · 英文原文
Aaron Ames co-authored FROST with Hereid, providing a public MATLAB tool for gait planning.
证据范围 · 英文原文
Caltech repository attribution and simulation examples; authorship is shared and examples concern simulation.
来源
Aaron Prather E002Ecosystem Builders 50
贡献
行业测试研讨会
入选依据 · 英文原文
Aaron Prather co-organized a 2025 workshop bringing together research, industry and testing participants, with named presentation materials.
证据范围 · 英文原文
Workshop organization and presentation records; Beiter, Saidi, Sentis and other contributors retain their roles.
来源
Andra Keay E003Ecosystem Builders 50
贡献
机器人技术社群支持
入选依据 · 英文原文
Andra Keay provided advice, community connections and sustained support described in Women in Robotics records and Sue Keay’s account.
证据范围 · 英文原文
Organizational records and testimony from her sister; independent industry-wide effects remain unmeasured.
来源
Ayanna Howard E004Ecosystem Builders 50
贡献
无障碍 STEM 技术转移
入选依据 · 英文原文
Ayanna Howard describes founding Zyrobotics after NSF I-Corps participation and licensing laboratory technology into STEM products for children.
证据范围 · 英文原文
Howard’s university interview describes historical licensing and accessible STEM-product development.
来源
Brian Gerkey E005Ecosystem Builders 50
贡献
开放式机器人架构
入选依据 · 英文原文
Brian Gerkey co-designed ROS and ROS 2 and helped connect open robotics development across institutions, including a documented NVIDIA collaboration.
证据范围 · 英文原文
Joint design and partner records; Tully Foote and the wider developer community retain their technical contributions.
来源
Bruce Leak E052Ecosystem Builders 50
贡献
创始人与董事会支持
入选依据 · 英文原文
Bruce Leak co-founded Playground and served on Agility Robotics’ board, supporting founders and capital access.
证据范围 · 英文原文
Founding and board-participation records; investment amounts, technical design and portfolio outcomes remain separately attributed.
来源
Cho Kyu-nam E047Ecosystem Builders 50
贡献
行业公开讨论
入选依据 · 英文原文
Cho Kyu-nam moderated a July 2024 discussion, asking concrete questions about industrial competitiveness, market entry and infrastructure.
证据范围 · 英文原文
The 2024-07-24 roundtable transcript records Cho’s questions and the participants’ responses.
来源
Christian Hubicki E007Ecosystem Builders 50
贡献
控制与仿真教育
入选依据 · 英文原文
Christian Hubicki led optimal-control and simulation teaching at IMSI, with links to code and answers for participants.
证据范围 · 英文原文
An IMSI workshop page provides Hubicki’s teaching record and links to code and answers.
来源
Craig Schlenoff E008Ecosystem Builders 50
贡献
机器人技术联合评估
入选依据 · 英文原文
Craig Schlenoff contributed conceptualization, project management, supervision and drafting to ARIAC’s shared evaluation work.
证据范围 · 英文原文
The available published contribution statement credits conceptualization, project management, supervision and drafting of the shared ARIAC evaluation work.
来源
Cyril Ebersweiler E053Ecosystem Builders 50
贡献
硬件初创企业支持
入选依据 · 英文原文
Cyril Ebersweiler helped found and operate HAX, with Neptune Robotics documenting use and subsequent support.
证据范围 · 英文原文
Shared incubator and beneficiary records; beneficiary technology and investment-wide outcomes retain separate attribution.
来源
Daniela Rus P006Ecosystem Builders 50
贡献
机器人技术博士生指导
入选依据 · 英文原文
Daniela Rus supervised Joseph DelPreto's completed doctorate and supported his research direction and lab community.
证据范围 · 英文原文
The dissertation identifies Rus as thesis supervisor and acknowledges her guidance; MIT separately credits Rus and DelPreto as Conduct-A-Bot coauthors.
来源
Dennis Hong E009Ecosystem Builders 50
贡献
研究与教育平台
入选依据 · 英文原文
Dennis Hong led RoMeLa’s public robotics platforms for research and education.
证据范围 · 英文原文
Platform and education records, with students, research teams and ROBOTIS sharing hardware and software contributions.
来源
Elena Messina E010Ecosystem Builders 50
贡献
联合标准与测试
入选依据 · 英文原文
Elena Messina contributed to named joint standards and testing outputs for robotics.
证据范围 · 英文原文
Documented joint standards and test contributions; individual and institutional functions retain separate attribution.
来源
Elham Tabassi E011Ecosystem Builders 50
贡献
AI 风险管理框架
入选依据 · 英文原文
Elham Tabassi authored NIST’s publicly available AI RMF 1.0, providing risk-management language reusable in Physical AI procurement and trust discussions.
证据范围 · 英文原文
NIST author attribution and framework publication; this is a cross-domain AI framework, with robot-specific safety certification assessed separately.
来源
Erico Guizzo E012Ecosystem Builders 50
贡献
机器人技术编辑资源
入选依据 · 英文原文
Erico Guizzo co-created the concept and content of Robots Guide, providing an editorial route into robotics knowledge.
证据范围 · 英文原文
Project attribution; Randi Klett, Evan Ackerman and the design and development teams retain shared contributions, with readership effects unmeasured.
来源
李飞飞 / Fei-Fei Li E013Ecosystem Builders 50
贡献
共享视觉数据集与挑战赛
入选依据 · 英文原文
Fei-Fei Li helped build ImageNet’s shared dataset and challenge, which drew participation from multiple institutions.
证据范围 · 英文原文
ImageNet’s historical data and 2010 challenge records identify shared author and organizer contributions.
来源
Francesca Rossi E014Ecosystem Builders 50
贡献
自主系统设计伦理
入选依据 · 英文原文
Francesca Rossi co-chaired IEEE EAD’s embedding-values committee and participated in named IBM research.
证据范围 · 英文原文
IEEE committee record and joint research; the contribution concerns public design knowledge rather than product certification.
来源
Geordie Rose P009Ecosystem Builders 50
贡献
机器人合作伙伴的投资和支持
入选依据 · 英文原文
Geordie Rose describes building robotics partnerships through investment and licensing; Apptronik's CEO credits his board support.
证据范围 · 英文原文
Sanctuary's signed retrospective and partner quotation describe corporate partnerships, investment and board support.
来源
Gill Pratt P010Ecosystem Builders 50
贡献
共享机器人测试项目统筹
入选依据 · 英文原文
Gill Pratt led DARPA's Robotics Challenge program, providing common disaster-response tasks and test conditions for competing robot teams.
证据范围 · 英文原文
DARPA identifies Pratt as program manager and describes human-supervised systems and degraded communications; participating teams contributed their hardware, software and algorithms.
来源
Han Jae-kwon E050Ecosystem Builders 50
贡献
面向公众的机器人教育
入选依据 · 英文原文
Han Jae-kwon and Lee Byung-joo delivered robotics lectures at Hanyang's August 2022 Robot Day.
证据范围 · 英文原文
Hanyang reports lectures, demonstrations and robot-making activities. The separate HERoEHS team paper credits Han with ALICE's mechanical design and Younseal Eum with exterior design.
来源
He Wang E044Ecosystem Builders 50
贡献
共享灵巧抓取基准测试和工具
入选依据 · 英文原文
He Wang was corresponding author of BODex's joint benchmark, data and code release; UltraDexGrasp documents adapting its code.
证据范围 · 英文原文
BODex names Jiayi Chen and Yubin Ke as equal contributors. UltraDexGrasp's README identifies its adapted BODex API and credits the upstream code.
来源
Henrik Christensen E015Ecosystem Builders 50
贡献
共享机器人技术路线图
入选依据 · 英文原文
Henrik Christensen served as a principal writer of repeated Robotics Roadmap editions, organizing a shared research agenda.
证据范围 · 英文原文
UCSD attribution and joint roadmap publications, with co-authors and workshop participants sharing the contribution.
来源
Jiyang Gao P036Ecosystem Builders 50
贡献
数据集和模型项目协调
入选依据 · 英文原文
Jiyang Gao co-supervised Galaxea's dataset-and-model research programme with Hang Zhao and Huazhe Xu. This entry recognizes coordination of the team's shared research capability.
证据范围 · 英文原文
The paper describes the dataset and G0 model; Section 8 names the three supervisors and separately credits dataset operations and policy training. Version 1 announced public release as a forthcoming step.
来源
Jung Kim E036Ecosystem Builders 50
贡献
初创企业发展项目
入选依据 · 英文原文
Jung Kim led KAIST’s Robot Valley program, with the university identifying actual startup-competition beneficiaries.
证据范围 · 英文原文
University program account; operations are shared and new model and robotic-skin plans retain planned status.
来源
Karol Hausman P015Ecosystem Builders 50
贡献
机器人学习基础设施
入选依据 · 英文原文
Karol Hausman contributed robot infrastructure and writing to pi0.5.
证据范围 · 英文原文
Appendix A-A attributes robot infrastructure and writing to Hausman within the joint research team.
来源
Li Zexiang E016Ecosystem Builders 50
贡献
创业教育和制造支持
入选依据 · 英文原文
Li Zexiang connects practical education with startup mentoring, early capital and supply-chain support through documented ecosystem-building work.
证据范围 · 英文原文
University account of shared X-Tech and XbotPark activities; company-specific effects and current support outcomes lack independent measurement.
来源
Liang Jing E037Ecosystem Builders 50
贡献
标准工作组运作
入选依据 · 英文原文
Liang Jing organized and chaired work described in official annual-meeting records, including organizational reporting and an open project call.
证据范围 · 英文原文
Official meeting record; standards-system publication and individual product testing or certification have separate scope.
来源
Lior Susan E051Ecosystem Builders 50
贡献
工业初创企业的组建
入选依据 · 英文原文
Lior Susan helped establish Eclipse and organized Bright Machines’ founding, separation and funding support.
证据范围 · 英文原文
Participant interview concerning startup and organizational work; portfolio-wide results retain company and team attribution.
来源
Liu Lianqing E030Ecosystem Builders 50
贡献
机器人学博士生指导
入选依据 · 英文原文
Liu Lianqing supervised named completed doctoral research by Zhou Peilin.
证据范围 · 英文原文
Institute records of supervision and research; students and co-authors retain their technical contributions.
来源
Matt Beane E017Ecosystem Builders 50
贡献
关于工作与技能转型的研究
入选依据 · 英文原文
Matt Beane published long-term field research on robotic surgery and shadow learning, contributing knowledge about work and training transitions.
证据范围 · 英文原文
UCSB research account and published study; observations and measured effects of training-system changes have separate scope.
来源
Matthew Johnson-Roberson E018Ecosystem Builders 50
贡献
机器人学博士生指导
入选依据 · 英文原文
Matthew Johnson-Roberson advised Tianyi Zhang's completed doctorate on underwater 3D visual perception and generation.
证据范围 · 英文原文
CMU records the August 2025 doctorate and advisor. Johnson-Roberson also co-authored synthetic-data research described in Driving in the Matrix.
来源
Mayank Mittal E055Ecosystem Builders 50
贡献
机器人学习公共基础设施
入选依据 · 英文原文
Mayank Mittal led development work on Isaac Lab, providing public code reused in robotics learning research.
证据范围 · 英文原文
Development attribution and application research; NVIDIA, ETH and other developers retain shared credit, with full replication unperformed.
来源
Morgan Quigley E056Ecosystem Builders 50
贡献
ROS 架构
入选依据 · 英文原文
Morgan Quigley co-designed ROS and contributed to its architecture and public development infrastructure.
证据范围 · 英文原文
Original joint research and development records; roles are shared with Gerkey, Foote and other contributors.
来源
Pieter Abbeel E020Ecosystem Builders 50
贡献
机器人控制教育
入选依据 · 英文原文
Pieter Abbeel repeatedly provided robotics-control education with documented student activities.
证据范围 · 英文原文
Course and student-activity records; the contribution concerns education infrastructure, with company and investment outcomes separately attributed.
来源
Qin Xiugong E049Ecosystem Builders 50
贡献
共享标准术语
入选依据 · 英文原文
Qin Xiugong co-drafted a foundational standard whose terminology was reused in T/CESA 1450-2025.
证据范围 · 英文原文
Named joint drafting and later terminology references document the foundational standard’s reuse.
来源
Qu Daokui E048Ecosystem Builders 50
贡献
研究成果商业化
入选依据 · 英文原文
Qu Daokui describes commercializing research through a startup team and distinguishes company industrialization from institute research.
证据范围 · 英文原文
Field interview republished by the institute, describing the shared technology-transfer contribution.
来源
Russ Tedrake E022Ecosystem Builders 50
贡献
共享控制软件
入选依据 · 英文原文
Russ Tedrake helped initiate Drake with MIT and Toyota Research Institute.
证据范围 · 英文原文
Official Drake credits; other developers and the institutions retain joint development and support contributions.
来源
Ryan Gariepy E023Ecosystem Builders 50
贡献
开发者交流与教育
入选依据 · 英文原文
Ryan Gariepy repeatedly participated in and co-led ROSCon, supporting developer exchange and education.
证据范围 · 英文原文
ROSCon opening materials and committee records identify Gariepy’s repeated participation and joint organizing role.
来源
Rémi Cadène / Remi Cadene E024Ecosystem Builders 50
贡献
开源机器人学习工具
入选依据 · 英文原文
Rémi Cadène led LeRobot, whose development resources appear in external hardware workflows.
证据范围 · 英文原文
Leadership attribution and Trossen documentation; the library is jointly developed and external use has experimental version constraints.
来源
Shi Lin E039Ecosystem Builders 50
贡献
联合制定评估标准
入选依据 · 英文原文
Shi Lin co-authored YD/T 6770-2026, contributing to a common Physical AI evaluation framework.
证据范围 · 英文原文
National standards information names Shi Lin among the co-authors of YD/T 6770-2026.
来源
Sun Lining E025Ecosystem Builders 50
贡献
区域性研究与人才培养计划
入选依据 · 英文原文
Sun Lining describes establishing a research institute, degree programs and talent-development activities supporting regional industry.
证据范围 · 英文原文
University-published interview describing the historical activities.
来源
Tom Ryden E026Ecosystem Builders 50
贡献
共享设施运营
入选依据 · 英文原文
Tom Ryden took on operations supporting shared facilities, programs and resident companies at MassRobotics.
证据范围 · 英文原文
Tom Ryden's March 2022 retrospective describes facility operations and programme development; the founding concept is credited to named founders.
来源
Tully Foote E027Ecosystem Builders 50
贡献
ROS 单位与坐标系规范
入选依据 · 英文原文
Tully Foote co-authored common ROS unit and coordinate conventions with Mike Purvis, supporting compatibility across developers.
证据范围 · 英文原文
Joint REP authorship and ROS 2 message conventions; technical conventions and institutional coordination have distinct attribution.
来源
Vincent Vanhoucke E028Ecosystem Builders 50
贡献
研究团队组建
入选依据 · 英文原文
Vincent Vanhoucke established a Google robotics research team and participated in subsequent joint research.
证据范围 · 英文原文
Historical official profile and joint outputs; team formation and support are distinguished from individual algorithm design.
来源
Wang Tianmiao E043Ecosystem Builders 50
贡献
人才与初创企业支持
入选依据 · 英文原文
Wang Tianmiao supported talent and startup development, with Beihang naming beneficiaries and documenting a scholarship donation.
证据范围 · 英文原文
Beihang’s commemorative account describes talent support, named startup beneficiaries and a scholarship donation.
来源
Wei Kai E045Ecosystem Builders 50
贡献
联合制定评估标准
入选依据 · 英文原文
Wei Kai co-authored YD/T 6770-2026, contributing to a specific Physical AI evaluation output.
证据范围 · 英文原文
National standards author listing; evidence covers shared authorship rather than sole clause design or operation of testing institutions.
来源
Wendy Tan White E054Ecosystem Builders 50
贡献
共享开发组织
入选依据 · 英文原文
Wendy Tan White organized shared robotics development through integration of OSRC’s business and staff, with partner use in actual development tasks.
证据范围 · 英文原文
Management and partner-use records; Gerkey, Kroeger, NVIDIA, DeepMind and other technical contributors retain their roles.
来源
Xiong Rong E032Ecosystem Builders 50
贡献
学生研究平台
入选依据 · 英文原文
Xiong Rong guided Zhejiang University's robotics competition training and its ZJUNlict student team.
证据范围 · 英文原文
Zhejiang University's November 2007 teaching report names Xiong as supervisor of robotics training. ZJUNlict's team description credits her guidance and successive student teams.
来源
Yuh Joon-ku E041Ecosystem Builders 50
贡献
研究议程编辑
入选依据 · 英文原文
Yuh Joon-ku co-edited a research-direction workshop report, providing a historical public research and education resource.
证据范围 · 英文原文
University publication list and NOAA-preserved report cover from 1994 to 1996; evidence concerns joint editing.
来源
Zhang Jianwei E029Ecosystem Builders 50
贡献
跨机构研究协调
入选依据 · 英文原文
Zhang Jianwei coordinated the six-institution RACE robotics consortium from December 2011 to November 2014.
证据范围 · 英文原文
Hamburg names Zhang as coordinator; the joint PR2 evaluation paper credits its authors for architecture, metrics and physical restaurant-task research.
来源
ARM Institute I001Institutions 50
贡献
制造业应用推广支持
入选依据 · 英文原文
ARM Institute helped Keystone Ridge move from evaluation and proof of concept through an RFP to installation of a robot cell.
证据范围 · 英文原文
Institute case with customer quotations; evidence concerns the named adoption pathway.
来源
ASTM F45 I003Institutions 50
贡献
移动机器人性能标准
入选依据 · 英文原文
ASTM F45 provides performance-test standards for unmanned mobile tasks, with NIST documenting the technical basis of its first four standards.
证据范围 · 英文原文
NIST’s 2018 record documents publication of ASTM F45’s first four mobile-task performance standards.
来源
Beijing Humanoid Robot Innovation Center I047Institutions 50
贡献
共享的机器人训练数据
入选依据 · 英文原文
Beijing Humanoid Robot Innovation Center co-developed RoboMIND, with government material naming external institutions using it for training.
证据范围 · 英文原文
Government development and use report; download counts and unique users are distinct measures, with independent use verification limited.
来源
BIGAI I004Institutions 50
贡献
共享的机器人研究工具
入选依据 · 英文原文
BIGAI co-authored RoboVerse, with RLinf documenting its integration into research workflows.
证据范围 · 英文原文
Named institutional co-authors and external integration account, with partner institutions and existing simulators sharing the contribution.
来源
CESI I005Institutions 50
贡献
具身智能数据质量指导性文件共同起草
入选依据 · 英文原文
CESI is a joint drafting organization for GB/Z 218.1-2026, guidance on real-data quality for embodied intelligence, published on 27 August 2026.
证据范围 · 英文原文
The official record classifies the document as technical guidance and lists CESI among its drafters. TC28 has committee responsibility, TC28SC42 is the executing body, and SAC is the supervisory authority.
来源
CMU Robotics Institute I006Institutions 50
贡献
机器人技术研究与教育
入选依据 · 英文原文
CMU’s Robotics Institute supports robotics research and education. Its NREC partnered with Carnegie Robotics to commercialize robotic components and systems.
证据范围 · 英文原文
CMU’s 2010 partnership record documents NREC technology transfer to Carnegie Robotics; NREC remains within the institute’s activity record.
来源
DARPA SubT I007Institutions 50
贡献
共享物理测试环境
入选依据 · 英文原文
DARPA’s SubT competition provided shared physical test environments and tasks used by teams including CSIRO Data61, Emesent and Georgia Tech.
证据范围 · 英文原文
Participant account of the competition ending in 2021; team-developed robots and autonomy retain separate attribution.
来源
DFKI Robotics Innovation Center I008Institutions 50
贡献
工业机器人研究
入选依据 · 英文原文
DFKI’s Robotics Innovation Center participated in TransFit research with Bremen and Siemens, producing joint research outputs.
证据范围 · 英文原文
The 2017 to 2021 TransFit record covers German research collaboration and published outputs.
来源
ETRI I009Institutions 50
贡献
机器人技术转让
入选依据 · 英文原文
ETRI transferred FMS to Twinny and supported recipient-specific joint development through staff working at the company.
证据范围 · 英文原文
ETRI Webzine Vol.225 documents FMS transfer to Twinny, on-site staff support and joint software adaptation for people working alongside robots.
来源
euRobotics I010Institutions 50
贡献
机器人研究生态系统
入选依据 · 英文原文
CORDIS records euRobotics’ coordination of RockEU2 and the launch and operation of two ERL seasons.
证据范围 · 英文原文
Completed project and competition records; market forecasts retain forecast status.
来源
FAA I011Institutions 50
贡献
超视距(BVLOS)包裹递送授权
入选依据 · 英文原文
The FAA authorized Zipline to deliver commercial packages beyond visual line of sight in 2023, establishing a defined regulatory route for the operator.
证据范围 · 英文原文
The FAA’s 2023 authorization covers Zipline commercial-package delivery beyond visual line of sight under the specified approval scope.
来源
Harvard Wyss Institute I012Institutions 50
贡献
辅助机器人研究与许可
入选依据 · 英文原文
Harvard Wyss and SEAS researchers developed personalized soft-exosuit assistance from muscle ultrasound and tested it across walking speeds and inclines. Wyss also records technology licensing to ReWalk.
证据范围 · 英文原文
Harvard’s November 2021 account documents joint Wyss and SEAS research and walking tests. The ReWalk licensing record covers a separate technology-transfer activity.
来源
HIT Robotics Technology and Systems Research Unit I013Institutions 50
贡献
实体机器人研究基础设施
入选依据 · 英文原文
HIT’s robotics technology and systems research unit supported a learning-method project through resources, supervision and physical-robot experiments.
证据范围 · 英文原文
Project acknowledgments, resource and supervision records, and physical experiments describe the research unit’s support; authors retain algorithm credit.
来源
HKEX / HKSCC I014Institutions 50
贡献
上市与结算准入
入选依据 · 英文原文
HKEX and HKSCC provided listing and clearing access used by UBTECH, whose listing began on 2023-12-29.
证据范围 · 英文原文
Issuer listing confirmation and clearing notice; the notice supplies no actual fundraising amount.
来源
IEC Robotics Product Safety Standards I015Institutions 50
贡献
机器人产品安全标准
入选依据 · 英文原文
IEC robotics-product safety work provides a lawn-robot standard edition cited in a manufacturer’s conformity declaration.
证据范围 · 英文原文
Standard edition and manufacturer declaration; the declaration and an IEC-issued product certificate have different status.
来源
IFR I016Institutions 50
贡献
机器人统计数据与定义
入选依据 · 英文原文
IFR provides recurring robot statistics and definitions through a documented collection and publication structure.
证据范围 · 英文原文
Industrial and service robotics statistics; coverage differs from the full Physical AI sector and company rankings.
来源
ISO/TC 299 I017Institutions 50
贡献
机器人标准制定
入选依据 · 英文原文
ISO/TC 299 develops shared robotics standards through published outputs, participating countries and industrial organizations.
证据范围 · 英文原文
Committee and publication records distinguish published standards from standards under development.
来源
KAIST I018Institutions 50
贡献
共享人形机器人研究平台
入选依据 · 英文原文
KAIST’s HUBO platform supports outside research and education. Drexel describes using HUBO Lab hardware and student software in performances and joint research.
证据范围 · 英文原文
External-user account; university, laboratory and center contributions remain within one institutional record.
来源
KEIT I020Institutions 50
贡献
机器人研究经费
入选依据 · 英文原文
KEIT supported humanoid balance-recovery research whose paper identifies the funded project and partial support.
证据范围 · 英文原文
2011 paper acknowledgment; KEIT’s funding and management role is distinct from the researchers’ algorithms and experiments.
来源
KIAT I022Institutions 50
贡献
机器人研发经费
入选依据 · 英文原文
KIAT funded project P0014166, whose researchers reported implementation and experiments on a robotics safety testbed.
证据范围 · 英文原文
Completed paper and funding acknowledgment; KIAT provided support while KIRIA researchers implemented and tested the system.
来源
KIRIA I023Institutions 50
贡献
机器人测试与认证
入选依据 · 英文原文
KIRIA issued KS certification for a wearable-robot product, confirmed in Hyundai’s announcement.
证据范围 · 英文原文
Hyundai's announcement identifies KIRIA's KS certification of the specified non-powered wearable product.
来源
KITECH I024Institutions 50
贡献
机器人数字孪生研究
入选依据 · 英文原文
KITECH researchers connected a physical robot with Isaac Sim and compared forward motion, turning and LiDAR messages.
证据范围 · 英文原文
Completed digital-twin implementation research; automated learning parameters and quantitative network-loss evaluation remain future tasks.
来源
KRX I050Institutions 50
贡献
机器人企业上市与信息披露准入
入选依据 · 英文原文
KRX provided KOSPI listing and trading access for Doosan Robotics, documented by the issuer’s completed listing and contract records.
证据范围 · 英文原文
Issuer listing records; subscription deposits and bookbuilding demand have separate scope from newly received issuer funds.
来源
KTL I025Institutions 50
贡献
可穿戴机器人测试
入选依据 · 英文原文
KTL provided testing used by Dari Technology, whose history records wearable-robot IP55, payload and weight test reports.
证据范围 · 英文原文
Recipient’s test-report history; evidence concerns these specific external tests.
来源
LeRobot / Hugging Face I026Institutions 50
贡献
共享机器人学习基础设施
入选依据 · 英文原文
LeRobot provides public code and data formats integrated into an external Trossen hardware workflow.
证据范围 · 英文原文
Project resources and experimental external documentation with version constraints; repository popularity has a different scope from active deployments.
来源
MassRobotics I027Institutions 50
贡献
共享开发设施
入选依据 · 英文原文
MassRobotics operates shared development space and experimental resources for named resident companies.
证据范围 · 英文原文
Resident and program records; the residency program provides access and states that it supplies no direct funding or equity investment.
来源
MIIT I028Institutions 50
贡献
机器人应用政策
入选依据 · 英文原文
MIIT jointly implemented selection and dissemination of 2024 mining-robot applications under the Robot+ plan.
证据范围 · 英文原文
The final application-selection notice records joint policy implementation with the mining-safety authority.
来源
MIT CSAIL I029Institutions 50
贡献
人机交互研究
入选依据 · 英文原文
MIT CSAIL conducted gesture-control research connecting EMG, learning and physical-drone experiments, with partial Boeing support.
证据范围 · 英文原文
Joint DelPreto and Rus research; Boeing’s role is funding, and Parrot retains drone-hardware credit.
来源
NASA Jet Propulsion Laboratory I030Institutions 50
贡献
行星机器人作业
入选依据 · 英文原文
JPL built and operated a Mars rover whose records describe autonomous perception, planning and physical driving.
证据范围 · 英文原文
Official account accompanying an animation of 2023-07-15 drive data; destination setting and ground-team planning remain part of operations.
来源
Nasdaq I031Institutions 50
贡献
机器人企业进入公开市场
入选依据 · 英文原文
Nasdaq provided public-market access for Serve through a completed share offering and Nasdaq Capital Market trading.
证据范围 · 英文原文
2024 issuer record; USD 40 million is gross offering proceeds before costs, and the overallotment option has separate execution status.
来源
National Robot Testing and Evaluation Center, Shanghai Headquarters I048Institutions 50
贡献
上海机器人认证
入选依据 · 英文原文
The National Robot Testing and Evaluation Center's Shanghai headquarters issued CR certification for AgiBot Genie G2 through Shanghai Robot Industry Technology Research Institute.
证据范围 · 英文原文
The July 2026 report names the Shanghai implementing carrier; the platform page separately identifies Shanghai Electrical Apparatus Research Institute (Group) Co., Ltd. as the headquarters construction unit.
来源
New York Stock Exchange / NYSE I053Institutions 50
贡献
发行人既往交易渠道
入选依据 · 英文原文
NYSE provided historical trading access for Ouster, recorded in the issuer’s 2021 annual report.
证据范围 · 英文原文
Historical issuer filing; Ouster’s announced December 2024 transfer to Nasdaq is a separate event.
来源
NHTSA I032Institutions 50
贡献
自动驾驶召回报告
入选依据 · 英文原文
NHTSA provides public safety-recall reporting, including Waymo's manufacturer-submitted report on an automated-driving flooding hazard.
证据范围 · 英文原文
Recall 26E026, submitted May 6, 2026, records interim operating restrictions and a final remedy under development at filing.
来源
NIOSH / Center for Occupational Robotics Research I054Institutions 50
贡献
职业环境下的机器人危害研究与指导
入选依据 · 英文原文
NIOSH contributed to joint workplace-robotics guidance and published fatality and nonfatal-injury research relevant to worker protection.
证据范围 · 英文原文
Joint guidance credits A3 engineers and NIOSH researchers. The 2023 fatality study covers 1992-2017; the 2026 NIOSH/Ohio study analyzes 1,076 claims from 2001-2020 and credits Ohio's data provision and the joint research team.
来源
NIST I033Institutions 50
贡献
机器人技术测量方法
入选依据 · 英文原文
NIST develops robot mobility measurements, tests and standards through an actual measurement program.
证据范围 · 英文原文
Specific robotics measurement outputs; safety certification and the wider AI RMF are separate functions.
来源
Open Robotics / OSRF I034Institutions 50
贡献
开放式机器人软件基础设施
入选依据 · 英文原文
The nonprofit OSRF provides and maintains open software used in robotics research and product development under the Open Robotics brand.
证据范围 · 英文原文
Organizational and software records; sold OSRC businesses and Intrinsic revenue retain separate legal and commercial scope.
来源
Open X-Embodiment consortium I035Institutions 50
贡献
共享学习数据与模型
入选依据 · 英文原文
Open X-Embodiment provides shared data formats and RT-X models used by multiple laboratories in physical-robot evaluations.
证据范围 · 英文原文
Named consortium research; participation counts vary by edition and rights differ across datasets.
来源
OSHA Robotics Safety Guidance I036Institutions 50
贡献
工作场所机器人安全指南
入选依据 · 英文原文
OSHA provides an updated robotics safety technical manual for inspectors and workplace safety staff.
证据范围 · 英文原文
2022 joint-guidance announcement; A3 engineering and NIOSH research retain separate contributions, with field inspection effects unmeasured.
来源
POSTECH I037Institutions 50
贡献
医院机器人联合研究与评估
入选依据 · 英文原文
POSTECH's Keehoon Kim and Jaewon Byun co-developed hospital disinfection robotics with KIST, KIRO, Elphoton and Pohang St. Mary's Hospital.
证据范围 · 英文原文
Institution-reported wiping and UV-C research and hospital evaluation; KIST's Sang-Rok Oh is named project director, and KIRO researchers retain joint credit.
来源
RAI Institute I038Institutions 50
贡献
公开的机器人学习工具
入选依据 · 英文原文
RAI Institute published learning code, Spot deployment methods and MIT-licensed research resources applied to Spot and Atlas hardware.
证据范围 · 英文原文
Published learning code and hardware methods for Spot and Atlas. The repository README identifies its maintenance status as inactive.
来源
SAC I039Institutions 50
贡献
国家标准管理
入选依据 · 英文原文
SAC is the supervisory authority for GB/Z 218.1-2026, the technical guidance document on real-data quality for embodied intelligence published on 27 August 2026.
证据范围 · 英文原文
The official record identifies TC28 committee responsibility and TC28SC42 execution. CESI and the other listed organizations share drafting credit; SAC’s supervisory role is separate.
来源
SEC I040Institutions 50
贡献
发行人信息披露审查
入选依据 · 英文原文
The SEC reviewed Serve disclosures, including questions about funding constraints and deployment outlook.
证据范围 · 英文原文
Actual review correspondence; filing effectiveness, secondary share sales and new proceeds retain separate regulatory and financial meanings.
来源
Shanghai AI Lab I041Institutions 50
贡献
共享仿真研究
入选依据 · 英文原文
Shanghai AI Lab’s InternUtopia was used for simulation evaluation by the named external EA-Nav research team.
证据范围 · 英文原文
External paper reporting use; public code and downloads have separate scope from physical commercial operations.
来源
Shanghai Stock Exchange I051Institutions 50
贡献
工业发行人市场准入
入选依据 · 英文原文
Shanghai Stock Exchange provided market access for welding-robot issuer Kaierda, with trading beginning on 2021-10-25 under 688255.
证据范围 · 英文原文
Official listing notice; the exchange provides a market channel, while company proceeds and revenues retain issuer-level scope.
来源
Shenzhen Stock Exchange I052Institutions 50
贡献
工业发行人市场准入
入选依据 · 英文原文
Shenzhen Stock Exchange provided listing and new-share fundraising access for industrial automation issuer Estun under 002747.
证据范围 · 英文原文
Official issuer-market announcement; the exchange is a market channel, with company-wide proceeds and revenues retaining their own scope.
来源
SIA I046Institutions 50
贡献
工业技术转移
入选依据 · 英文原文
SIA supported industrial-robot technology transfer through research-team commercialization and Siasun's formation.
证据范围 · 英文原文
The SIA-hosted historical account documents team and core-technology transfer. The Shenyang/Liaoning testing website identifies a separate location within the national testing network.
来源
Toyota Research Institute I042Institutions 50
贡献
机器人学习与控制研究
入选依据 · 英文原文
Toyota Research Institute co-developed and supported Drake and provided manipulation research and public benchmarks used in robotics work.
证据范围 · 英文原文
Development, research and benchmark-use records; Toyota manufacturing results and TRI research retain separate scope.
来源
UC Berkeley BAIR: RAIL BridgeData I043Institutions 50
贡献
共享机器人数据与训练工具
入选依据 · 英文原文
Berkeley RAIL’s BridgeData provides shared robot data, training code and access conditions used through documented external data-format workflows.
证据范围 · 英文原文
Evidence covers the RAIL activity within BAIR; shared Open X-Embodiment data events are cross-referenced without duplicate counting.
来源
XbotPark I044Institutions 50
贡献
初创企业制造支持
入选依据 · 英文原文
XbotPark provided startup funding support to Narwal, as described alongside direction-finding assistance in HKCRC material.
证据范围 · 英文原文
HKCRC’s account describes XbotPark funding support to Narwal, whose products and operating results retain company attribution.
来源
Zhejiang University Robotics Research I045Institutions 50
贡献
机器人技术教育
入选依据 · 英文原文
Zhejiang University provided robotics education using two Jueying robots brought by project leader Zhu Qiuguo for a completed course in September 2021.
证据范围 · 英文原文
EDP course record dated 2021-09-25 to 2021-09-26; evidence covers demonstration and interaction, with learning effects unmeasured.